DailyMechaTHE ROBOTICS BRIEFING
⌕
INDEPENDENT SOURCES. A CLEARER PICTURE.Sunday, October 25, 2026
DAILYMECHA / 논문

논문

Fresh research. Original abstracts preserved.

초기화
Latest submittedRecently updated
12 records · newest first
그리드목록
감각운동 정렬: 체화된 정책 성공을 위한 플라톤적 대리 지표

감각운동 정렬: 체화된 정책 성공을 위한 플라톤적 대리 지표

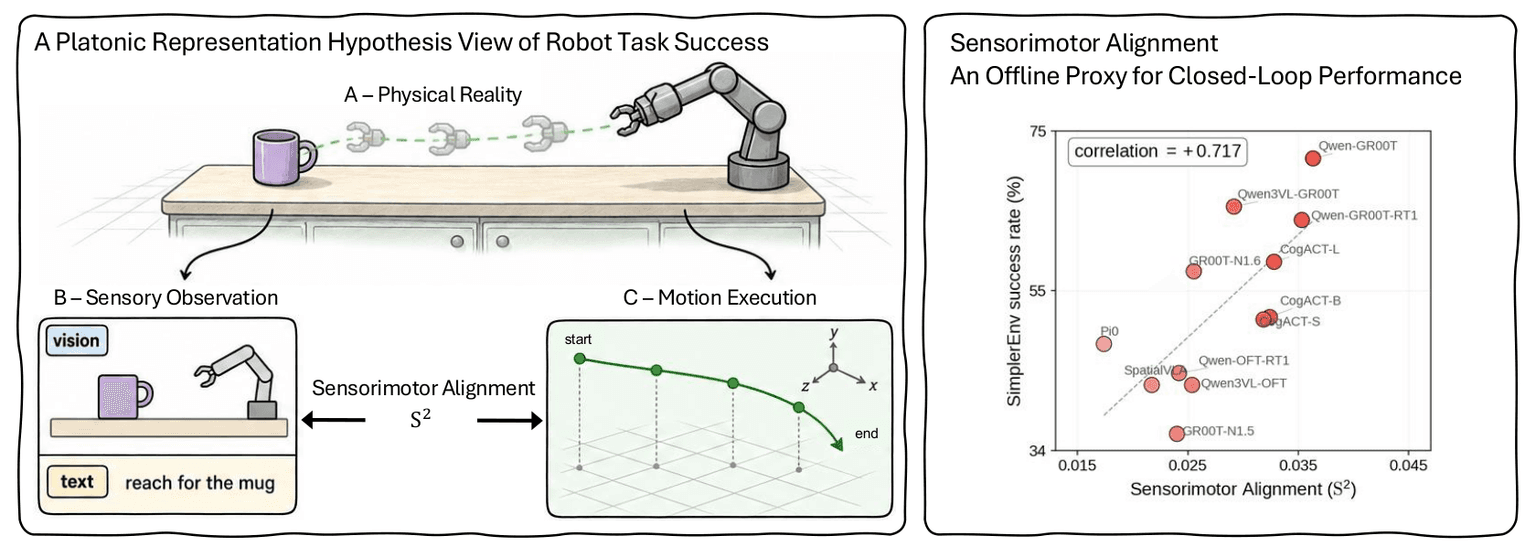
이 논문은 모델의 감각 표현을 말단 작동기 궤적으로 나타낸 물리적 운동의 기하학과 비교하는, 학습이 필요 없는 오프라인 지표인 감각운동 정렬(S²)을 제안한다. 12개의 비전-언어-행동 모델에서 S²는 후속 로봇 작업의 성공률과 양의 상관관계를 보인다. 저자들은 이를 미세 조정이나 비용이 많이 드는 폐루프 평가에 앞서 모델의 우선순위를 정하고 유망한 비전-언어 백본을 식별하는 저비용 방법으로 제시한다.

OpenTac: An Open Ecosystem for Customizable, Scalable, and Transferable 3D Tactile Sensing

OpenTac: An Open Ecosystem for Customizable, Scalable, and Transferable 3D Tactile Sensing

OpenTac combines a scalable resistive tactile skin with CAD, simulation, and data-acquisition tools for robot applications. Its structured deformable overlay encodes normal force and local shear from taxel responses. The authors report fabricating more than 30 sensor designs and demonstrate tactile feedback control and manipulation-policy learning on four real-world robot embodiments. Adaptive readout reaches kilohertz rates and is 19.2× faster than full-array raster scanning at 16 sampled taxels per update on a 1024-taxel skin.

번역 대기 · 영어 요약
AI 삽화 · 근궤적을 통한 조화함수 기법 확장으로 협응 경로 생성AI 삽화

근궤적을 통한 조화함수 기법 확장으로 협응 경로 생성

이 프리프린트는 다각형 장애물이 있는 평면 공간에서 서로 대체 가능한 로봇과 목표 지점을 위한 협응 경로를 연구한다. 제안된 구성은 등각 사상과 일반화된 근궤적을 사용해 로봇-목표 배정 및 경로를 도출한다. 저자들은 안전성 검사와 시뮬레이션 사례를 설명한다. DailyMecha는 초록을 요약했으며, 수학적 주장을 독립적으로 검증하지 않았다.

Progress Probes P²: 비전-언어-행동 모델을 위한 경량 런타임 모니터링

Progress Probes P²: 비전-언어-행동 모델을 위한 경량 런타임 모니터링

Progress Probes는 오픈소스 π0.5 비전-언어-행동 모델의 활성값으로 선형 프로브를 학습하고, 성공적인 시연을 활용해 작업 진행 상황을 추정합니다. 런타임 모니터는 추정된 진행 상황이 예상 궤적보다 뒤처지거나 벗어나는 실행을 표시합니다. 시뮬레이션 및 실제 조작 작업 전반에서 이 방법은 VLM 기반 모니터 및 실패 데이터를 학습에 사용한 방법과 대등하거나 더 나은 성능을 보였으며, 외부 파운데이션 모델은 필요하지 않았습니다.

어텐션 기반 접촉 계획을 통한 휴머노이드 이동성

어텐션 기반 접촉 계획을 통한 휴머노이드 이동성

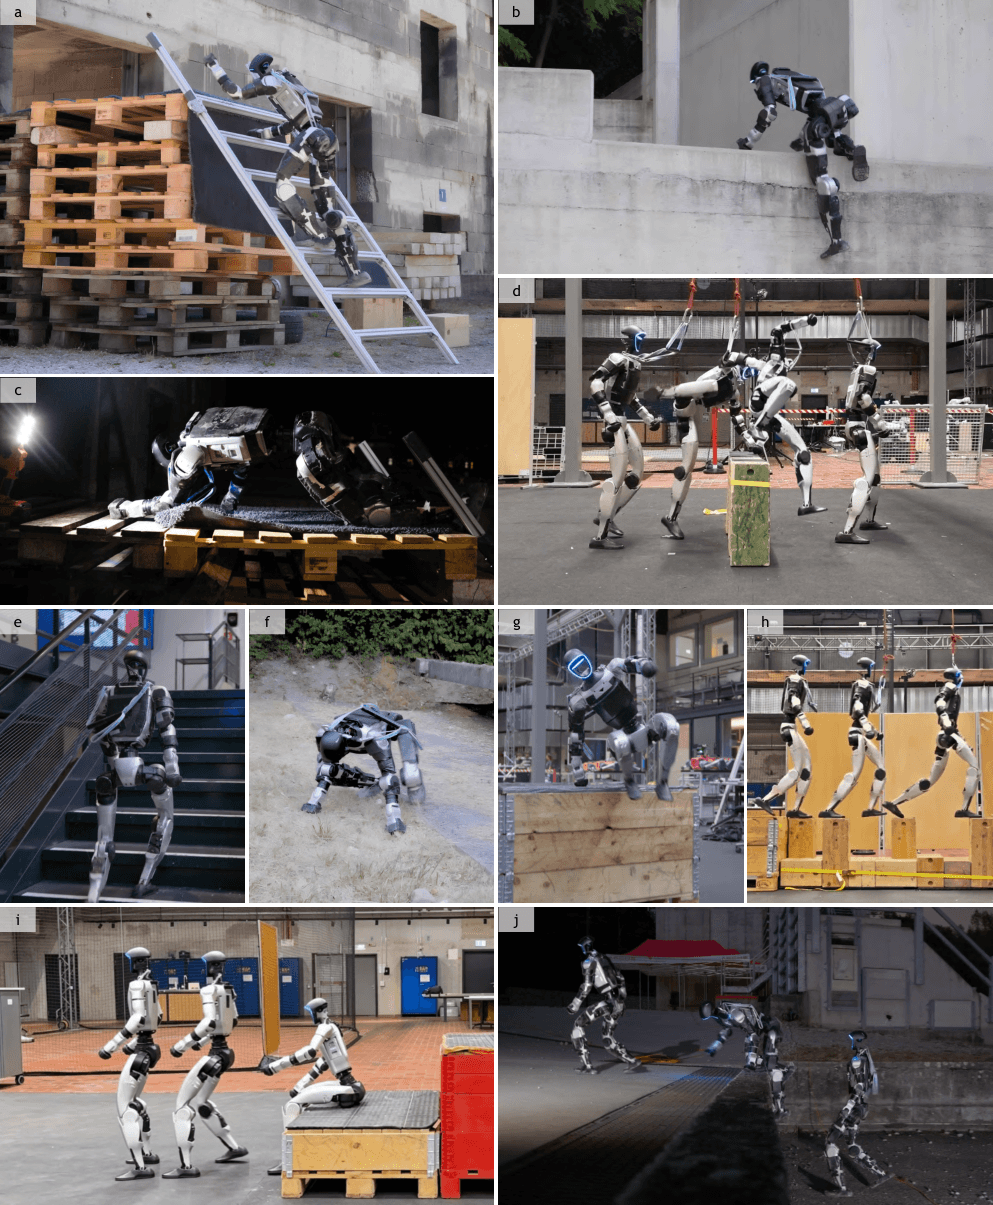
이 프레임워크는 어텐션 기반 접촉 계획기와 접촉 조건화 전신 추적기를 사용해 Unitree G1 휴머노이드를 제어합니다. 동작 데이터는 학습 사전 정보로만 사용되며, 강화학습 미세 조정을 통해 정책이 시연 데이터의 범위를 벗어난 지형 변화에도 대응하도록 합니다. 배포 시에는 기준 입력 없이 온보드 관측값을 사용하므로, 하나의 정책으로 사다리와 계단 오르기, 기어가기, 도약해 장애물 넘기, 징검다리 건너기 등의 작업을 수행할 수 있습니다.

Decentralized Bi-Level Optimization for Cooperative Orbital Transportation of a Rigid Payload

Decentralized Bi-Level Optimization for Cooperative Orbital Transportation of a Rigid Payload

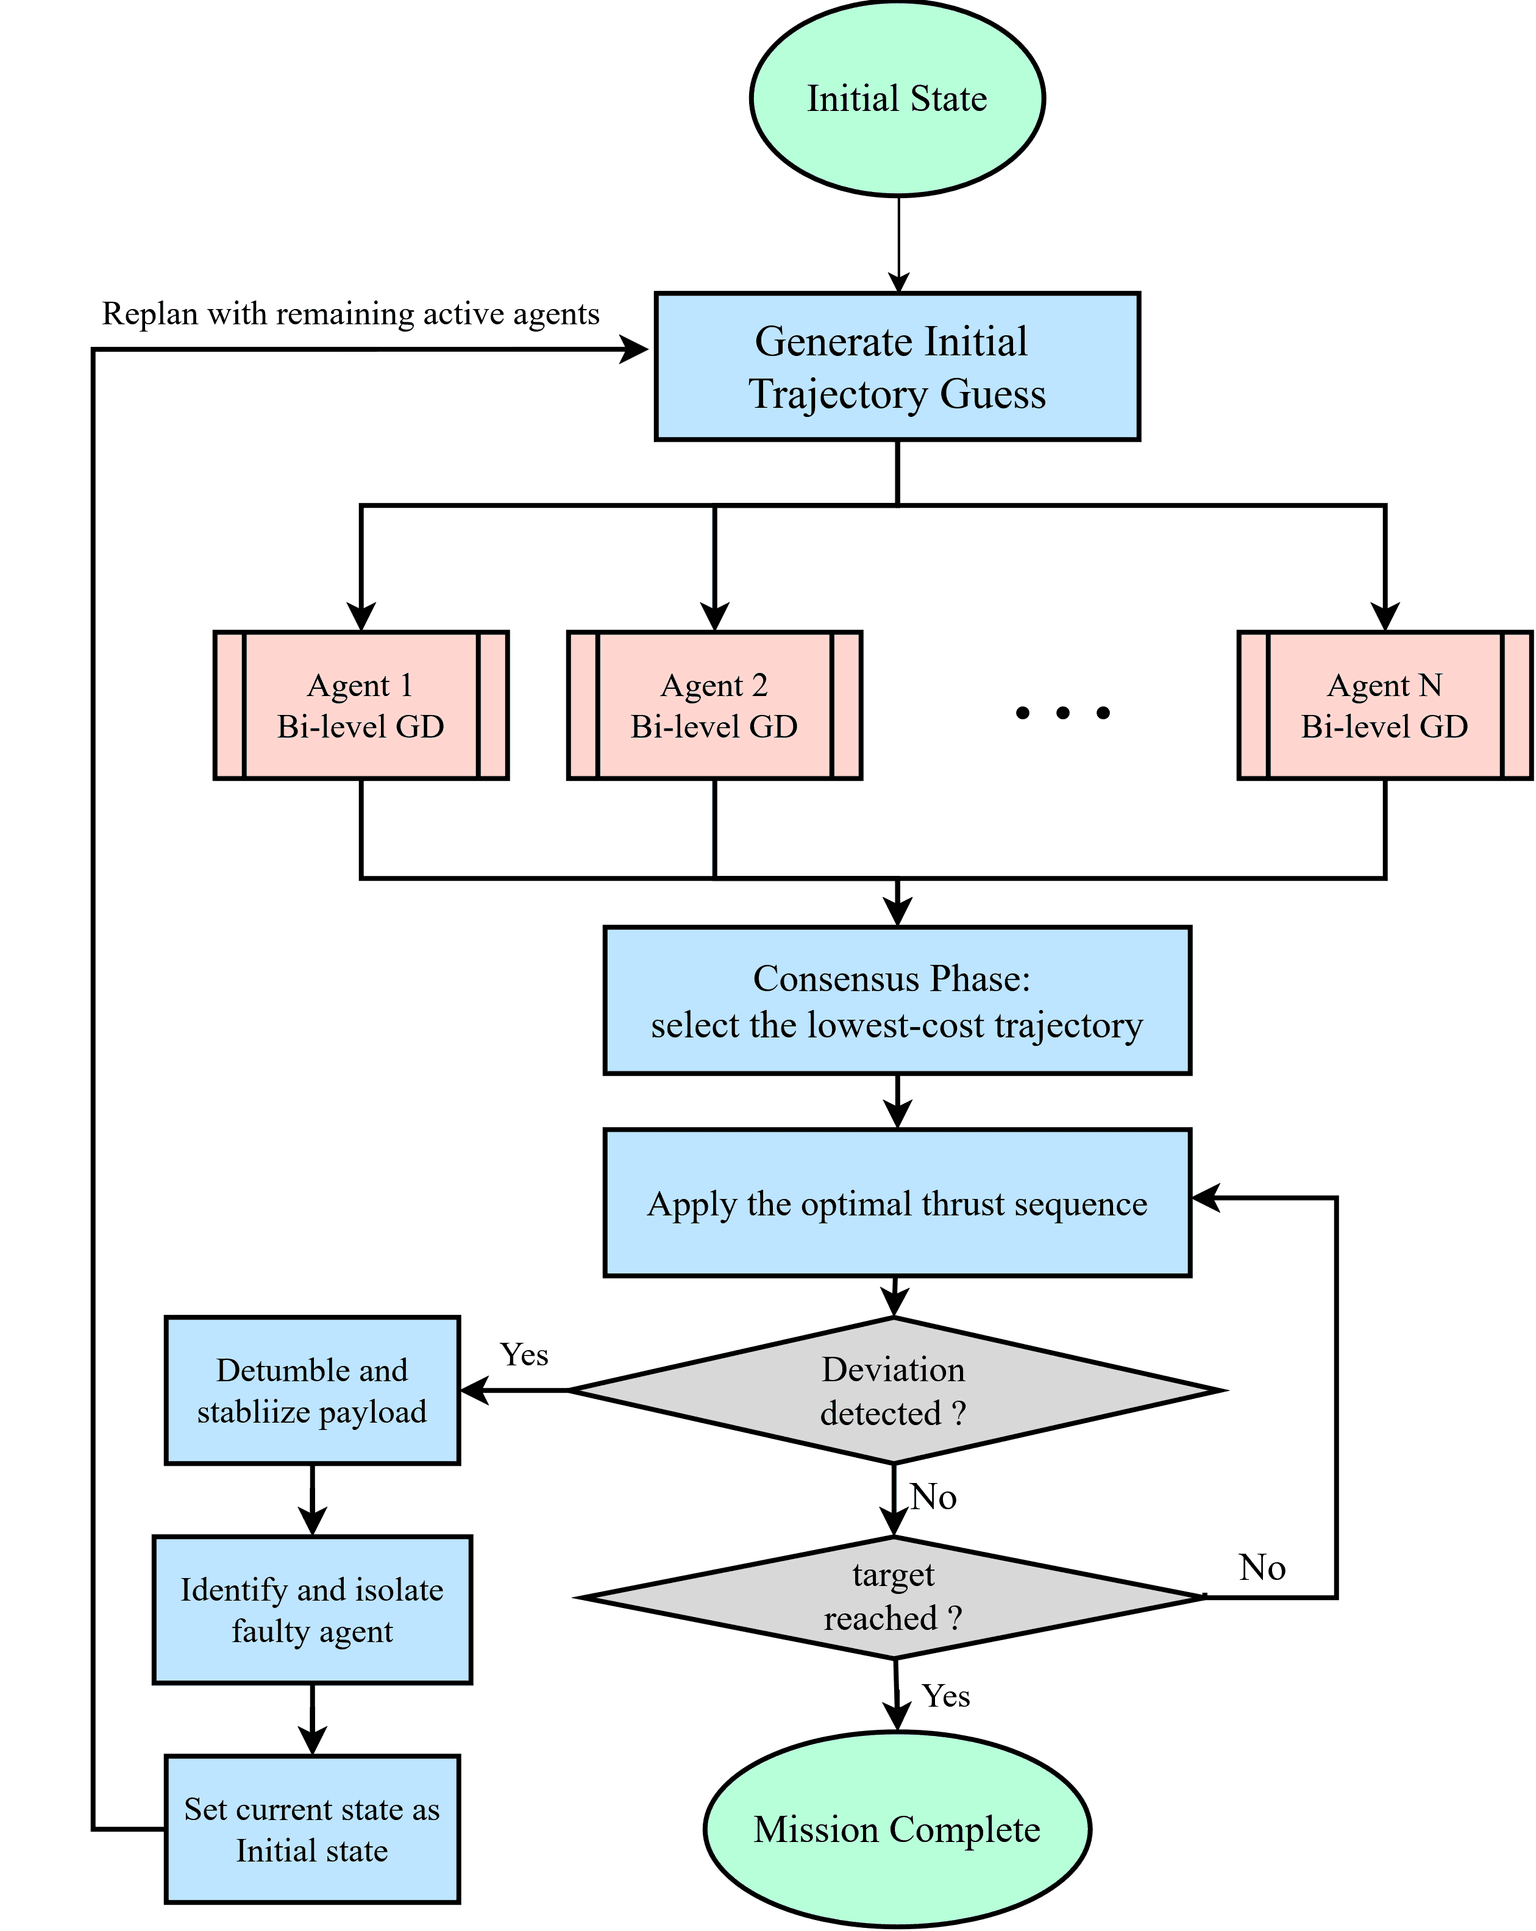
The paper presents a decentralized bi-level optimization framework for swarms of small spacecraft transporting a rigid payload. It separates convex thrust allocation from an outer search over payload torque trajectories, using exact gradients to find fuel-efficient solutions without requiring full nonlinear-program convergence. The authors report theoretical convergence guarantees and validate the method in extensive Monte Carlo simulations, including closed-loop recovery from in-flight faults; short-timescale performance scales with the number of agents.

번역 대기 · 영어 요약
SCOPE: Scene-graph Construction Optimized by Plan Error-correction for Robot Long-term Planning Datasets

SCOPE: Scene-graph Construction Optimized by Plan Error-correction for Robot Long-term Planning Datasets

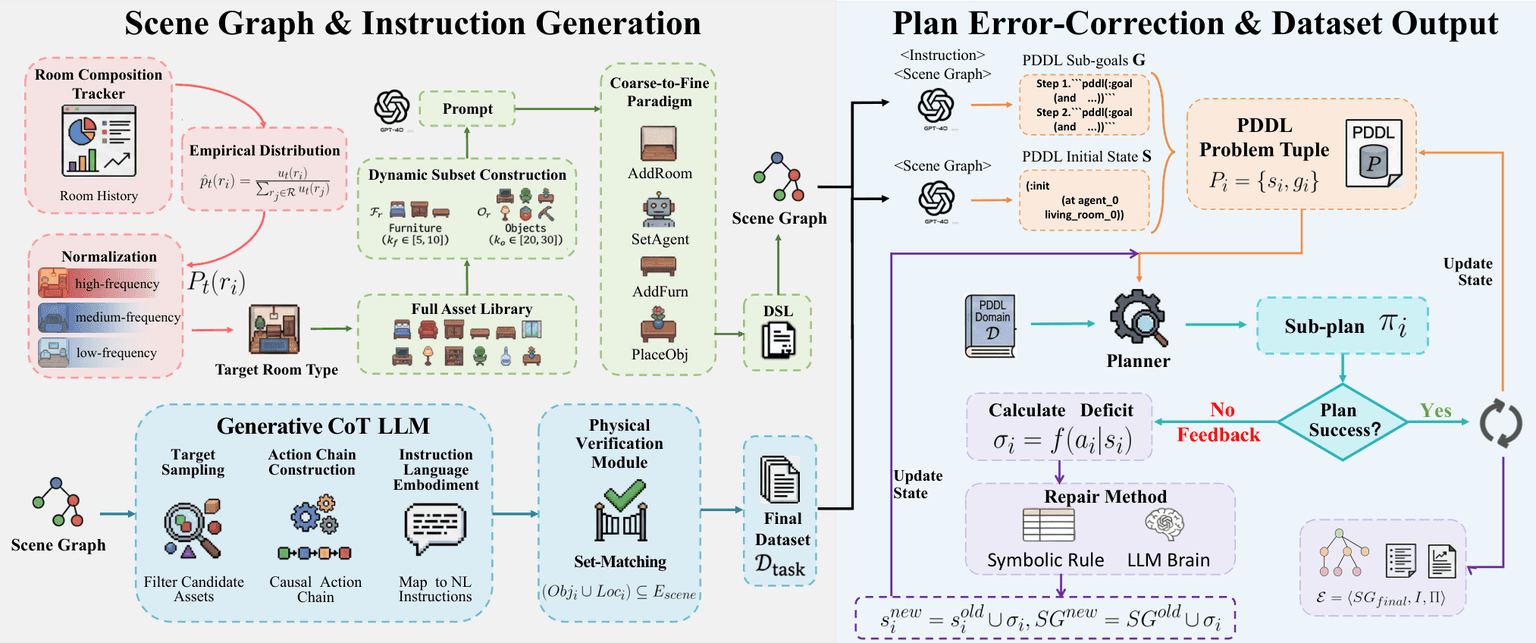
SCOPE is an automated framework for generating diverse, executable task-and-motion-planning datasets for robots. It uses planner execution failures to correct logical inconsistencies in scene graphs, aiming to ensure plans are physically feasible. In experiments, data generated by SCOPE improved a fine-tuned downstream TAMP model’s success rate by an absolute 12.33% over a counterpart trained on DELTA-generated data.

번역 대기 · 영어 요약
VecTile: A Low-Cost Flexible Tactile Array for 3-DoF Force Sensing

VecTile: A Low-Cost Flexible Tactile Array for 3-DoF Force Sensing

VecTile is a 6 mm-thin, flexible tactile array that uses a piezoresistive layer and silicone nubs to distinguish normal from shear forces. A 4×4 array costs less than $35; in single-taxel tests, normal- and shear-force errors were 0.39 N and 0.16 N RMS. The authors demonstrate balloon-safe scalpel contact and improved Diffusion Policy-guided power-plug insertion.

번역 대기 · 영어 요약
CoHelix: Event-Based Multi-Propeller Rotation-Rate Tracking with Shared Projective Geometry

CoHelix: Event-Based Multi-Propeller Rotation-Rate Tracking with Shared Projective Geometry

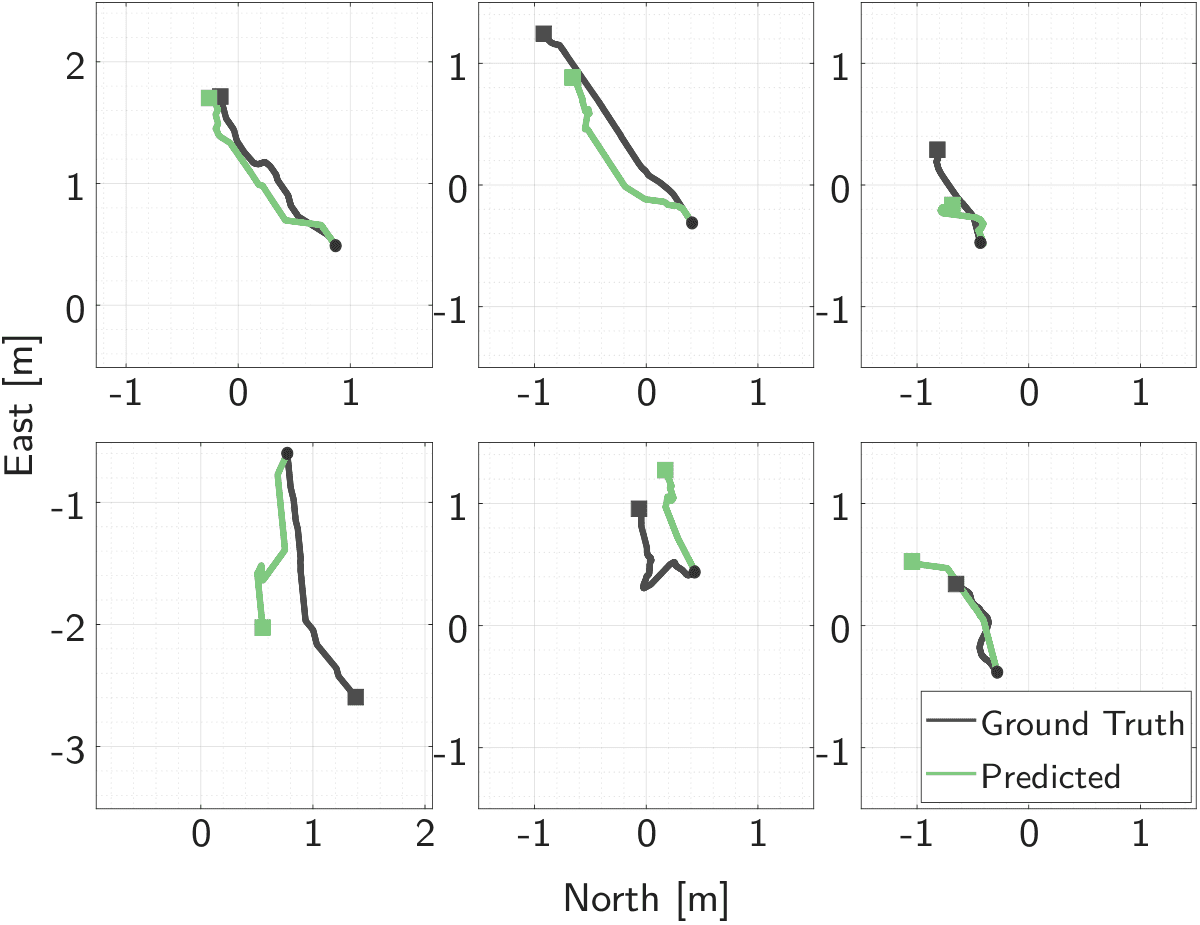
CoHelix is a recursive event-camera filter that tracks rotation rates for four rigidly mounted, coplanar quadcopter propellers while jointly estimating a shared image homography. On moving-camera recordings, it achieved 62.9% lock—time within 2% of synchronized ground truth—versus 39.8% for HelixTrack and 22.2% for EventPro. On a separate target-follower dataset, it reached 95.9% lock using measurement settings selected on the moving-camera data and a fixed initial rate.

번역 대기 · 영어 요약
GelSlim 5.0: Unifying Vision and Touch with a Single Fingertip Camera

GelSlim 5.0: Unifying Vision and Touch with a Single Fingertip Camera

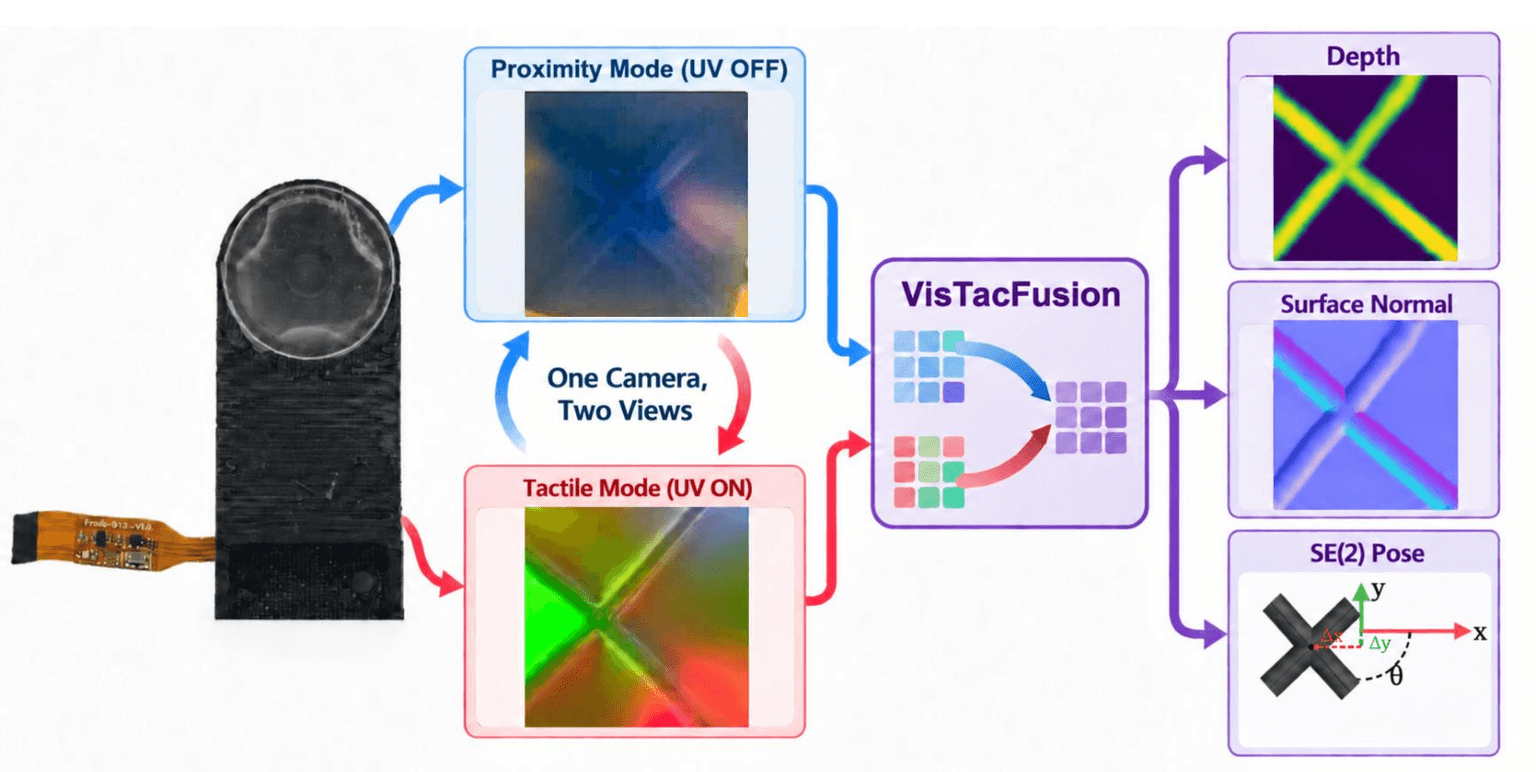
GelSlim 5.0 uses one fixed fingertip camera and a UV-responsive contact layer to capture visual and tactile images sequentially by switching illumination. The VisTacFusion transformer estimates planar object pose and contact depth and surface normals, with modality dropout supporting paired or single-modality inputs. On real validation data from 12 known objects, paired inputs reduced depth MSE by 61.2% versus tactile-only inference and 93.7% versus visual-only inference.

번역 대기 · 영어 요약
불확실성을 고려한 순응형 보조를 위한 전신 동작 기반 기준 궤적 생성

불확실성을 고려한 순응형 보조를 위한 전신 동작 기반 기준 궤적 생성

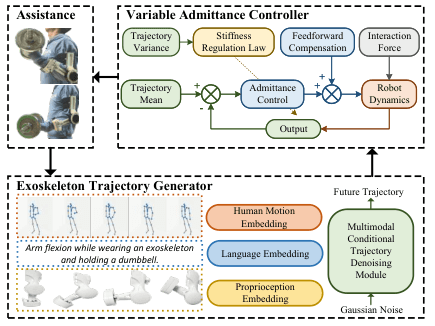
이 논문은 외골격 보조를 위한 이중 루프 제어 전략을 제안한다. 잡음 제거 생성기는 전신 인체 동작과 외골격 고유감각 정보를 사용하고, 작업 설명을 보조 단서로 활용해 미래 궤적을 생성한다. 제어기는 샘플링된 궤적의 평균을 기준값으로, 분산을 가변 어드미턴스 제어를 통한 강성 조절에 사용한다. 실험 결과, 표준 기준 방법보다 근육 활성도가 감소하고 무보조 조건보다 대사 에너지 소비가 낮은 것으로 나타났다.

Learning Robot Behavior Priors from Non-Robotic Synthetic Data

Learning Robot Behavior Priors from Non-Robotic Synthetic Data

The paper tests whether a Transformer can learn useful robot-action priors from procedurally generated data based on mathematical abstractions of control, without seeing real robot behavior during pretraining. The model achieves non-trivial zero-shot action prediction on unseen physical robot tasks through in-context learning; specialized control priors outperform generic causal priors. A compute-matched model trained on real robot data performs better only on the datasets it saw during training.

번역 대기 · 영어 요약

Verified published records only; coverage is not a census. arXiv preprints may not be peer reviewed. Official code is linked only after verification.