
GelSlim 5.0: Unifying Vision and Touch with a Single Fingertip Camera
번역을 준비 중입니다. 저장된 영어 요약을 먼저 표시합니다.
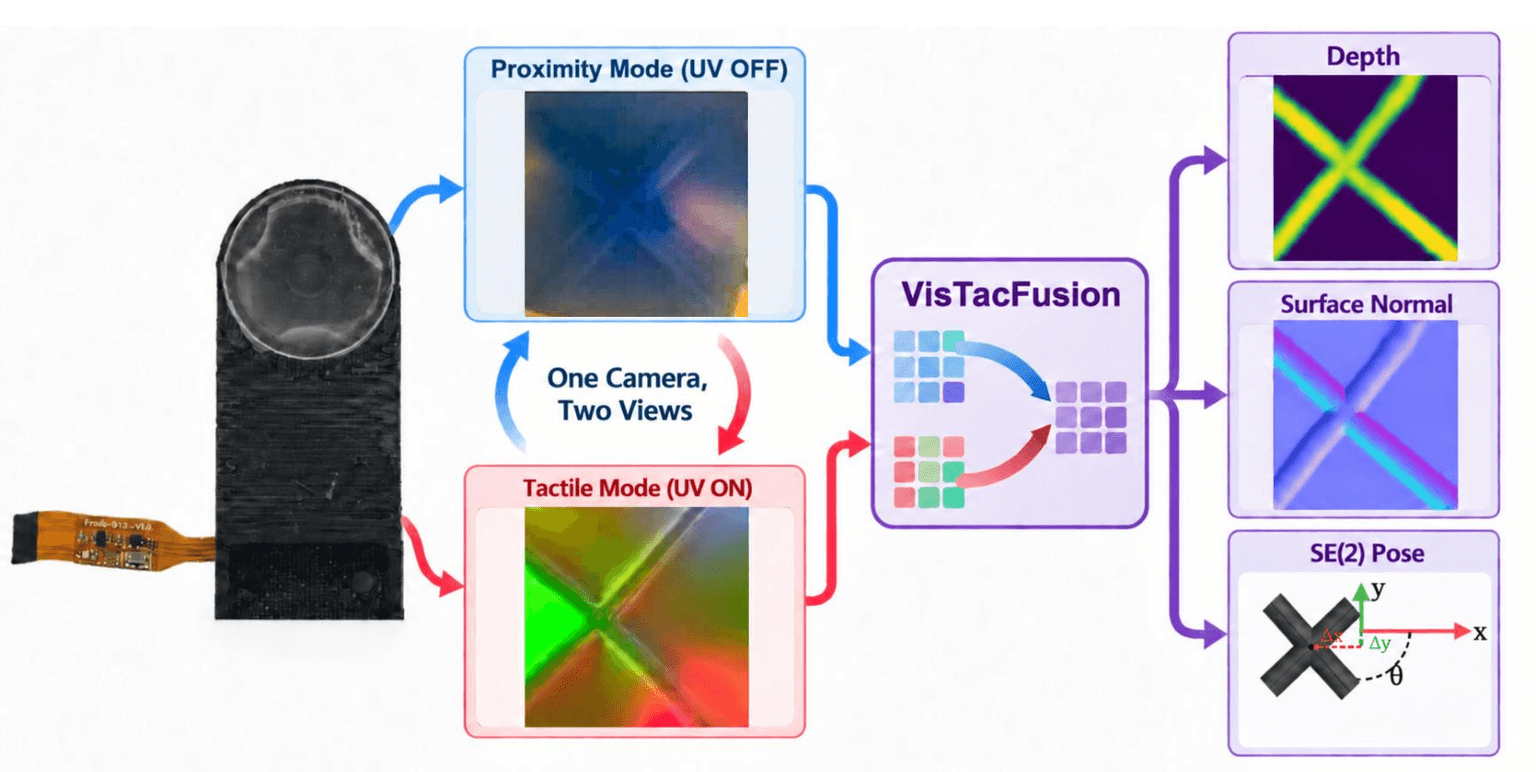
GelSlim 5.0 uses one fixed fingertip camera and a UV-responsive contact layer to capture visual and tactile images sequentially by switching illumination. The VisTacFusion transformer estimates planar object pose and contact depth and surface normals, with modality dropout supporting paired or single-modality inputs. On real validation data from 12 known objects, paired inputs reduced depth MSE by 61.2% versus tactile-only inference and 93.7% versus visual-only inference.
출처에 기반한 짧은 요약입니다. 기사 전문을 재게시하지 않으며 AI의 도움을 받아 작성·번역합니다.
논문 정보
Xiangdong Wang, I-Hsuan Huang, Xiaohao Xu, Xili Yi, Nima Fazeli, Xiaonan Huang
arXiv: 2610.31334 · v1
사전 공개 논문은 동료 심사를 마치지 않았을 수 있습니다.