DailyMechaTHE ROBOTICS BRIEFING
⌕
INDEPENDENT SOURCES. A CLEARER PICTURE.Sunday, October 25, 2026
DAILYMECHA / 论文

论文

Fresh research. Original abstracts preserved.

重置
Latest submittedRecently updated
12 records · newest first
网格列表
Sensorimotor Alignment: A Platonic Proxy for Embodied Policy Success

Sensorimotor Alignment: A Platonic Proxy for Embodied Policy Success

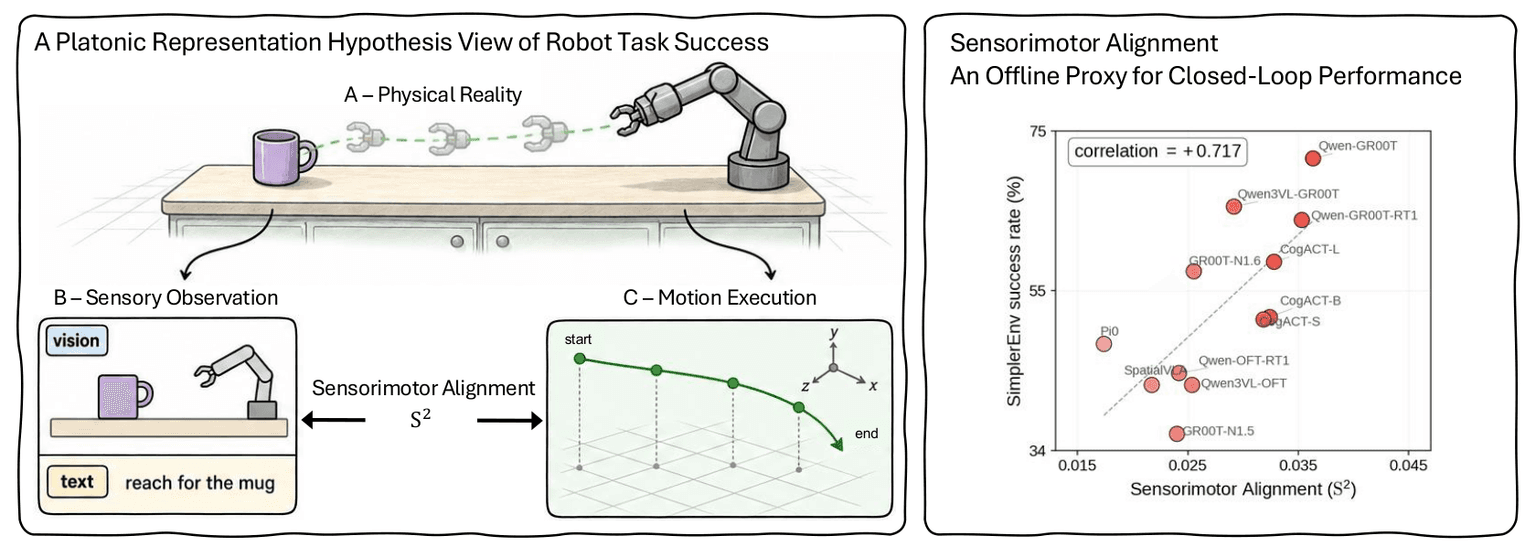
The paper proposes Sensorimotor Alignment (S²), a training-free offline metric that compares a model’s sensory representations with the geometry of physical motion, represented by end-effector trajectories. Across 12 vision-language-action models, S² positively correlates with downstream robot task success. The authors present it as a low-cost way to prioritize models and identify promising vision-language backbones before fine-tuning or costly closed-loop evaluation.

翻译待处理 · 英文摘要
OpenTac: An Open Ecosystem for Customizable, Scalable, and Transferable 3D Tactile Sensing

OpenTac: An Open Ecosystem for Customizable, Scalable, and Transferable 3D Tactile Sensing

OpenTac combines a scalable resistive tactile skin with CAD, simulation, and data-acquisition tools for robot applications. Its structured deformable overlay encodes normal force and local shear from taxel responses. The authors report fabricating more than 30 sensor designs and demonstrate tactile feedback control and manipulation-policy learning on four real-world robot embodiments. Adaptive readout reaches kilohertz rates and is 19.2× faster than full-array raster scanning at 16 sampled taxels per update on a 1024-taxel skin.

翻译待处理 · 英文摘要
AI 插画 · Extending Harmonic Function Methods via Root Locus for Coordinated Path GenerationAI 插画

Extending Harmonic Function Methods via Root Locus for Coordinated Path Generation

This preprint studies coordinated paths for interchangeable robots and goals in planar spaces with polygonal obstacles. The proposed construction uses conformal mapping and a generalized root locus to derive robot-goal assignments and paths. The authors describe safety tests and simulated examples. DailyMecha has summarized the abstract, without independently validating the mathematical claims.

翻译待处理 · 英文摘要
Progress Probes P²: Lightweight Runtime Monitoring for Vision-Language-Action Models

Progress Probes P²: Lightweight Runtime Monitoring for Vision-Language-Action Models

Progress Probes trains linear probes on activations from the open-source π0.5 vision-language-action model, using successful demonstrations to estimate task progress. At runtime, the monitor flags executions whose estimated progress lags or deviates from the expected trajectory. Across simulated and real-world manipulation tasks, the method was competitive with or outperformed VLM-based monitors and methods trained with failure data, without requiring an external foundation model.

翻译待处理 · 英文摘要
Humanoid Mobility via Attention-based Contacts

Humanoid Mobility via Attention-based Contacts

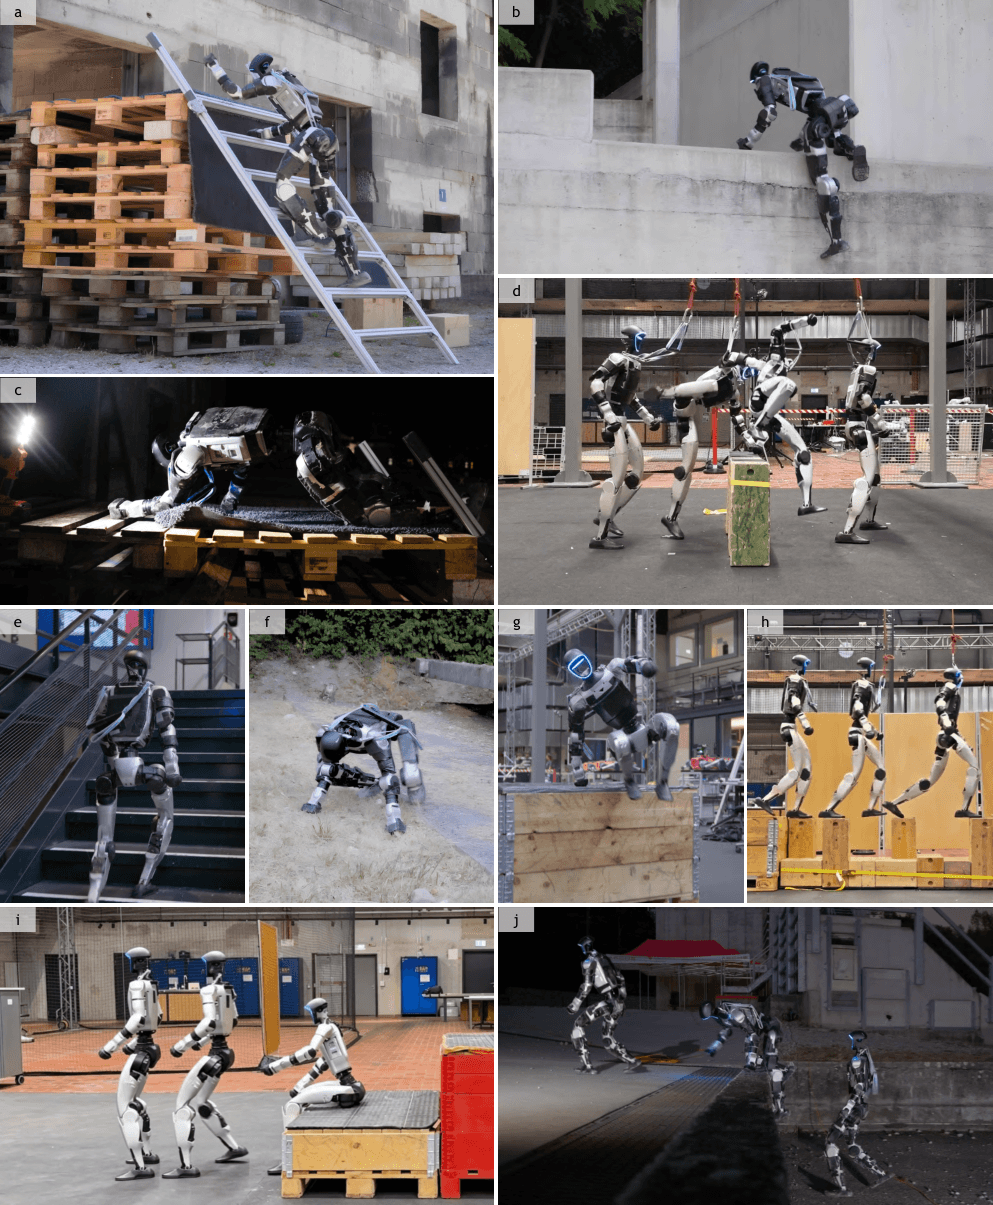
The framework controls a Unitree G1 humanoid using an attention-based contact planner and a contact-conditioned whole-body tracker. Motion data serves only as a training prior; reinforcement-learning fine-tuning helps the policy handle terrain variations beyond the demonstrations. At deployment, it uses onboard observations without reference inputs, enabling one policy to perform tasks including ladder and stair climbing, crawling, vaulting, and stepping-stone traversal.

翻译待处理 · 英文摘要
Decentralized Bi-Level Optimization for Cooperative Orbital Transportation of a Rigid Payload

Decentralized Bi-Level Optimization for Cooperative Orbital Transportation of a Rigid Payload

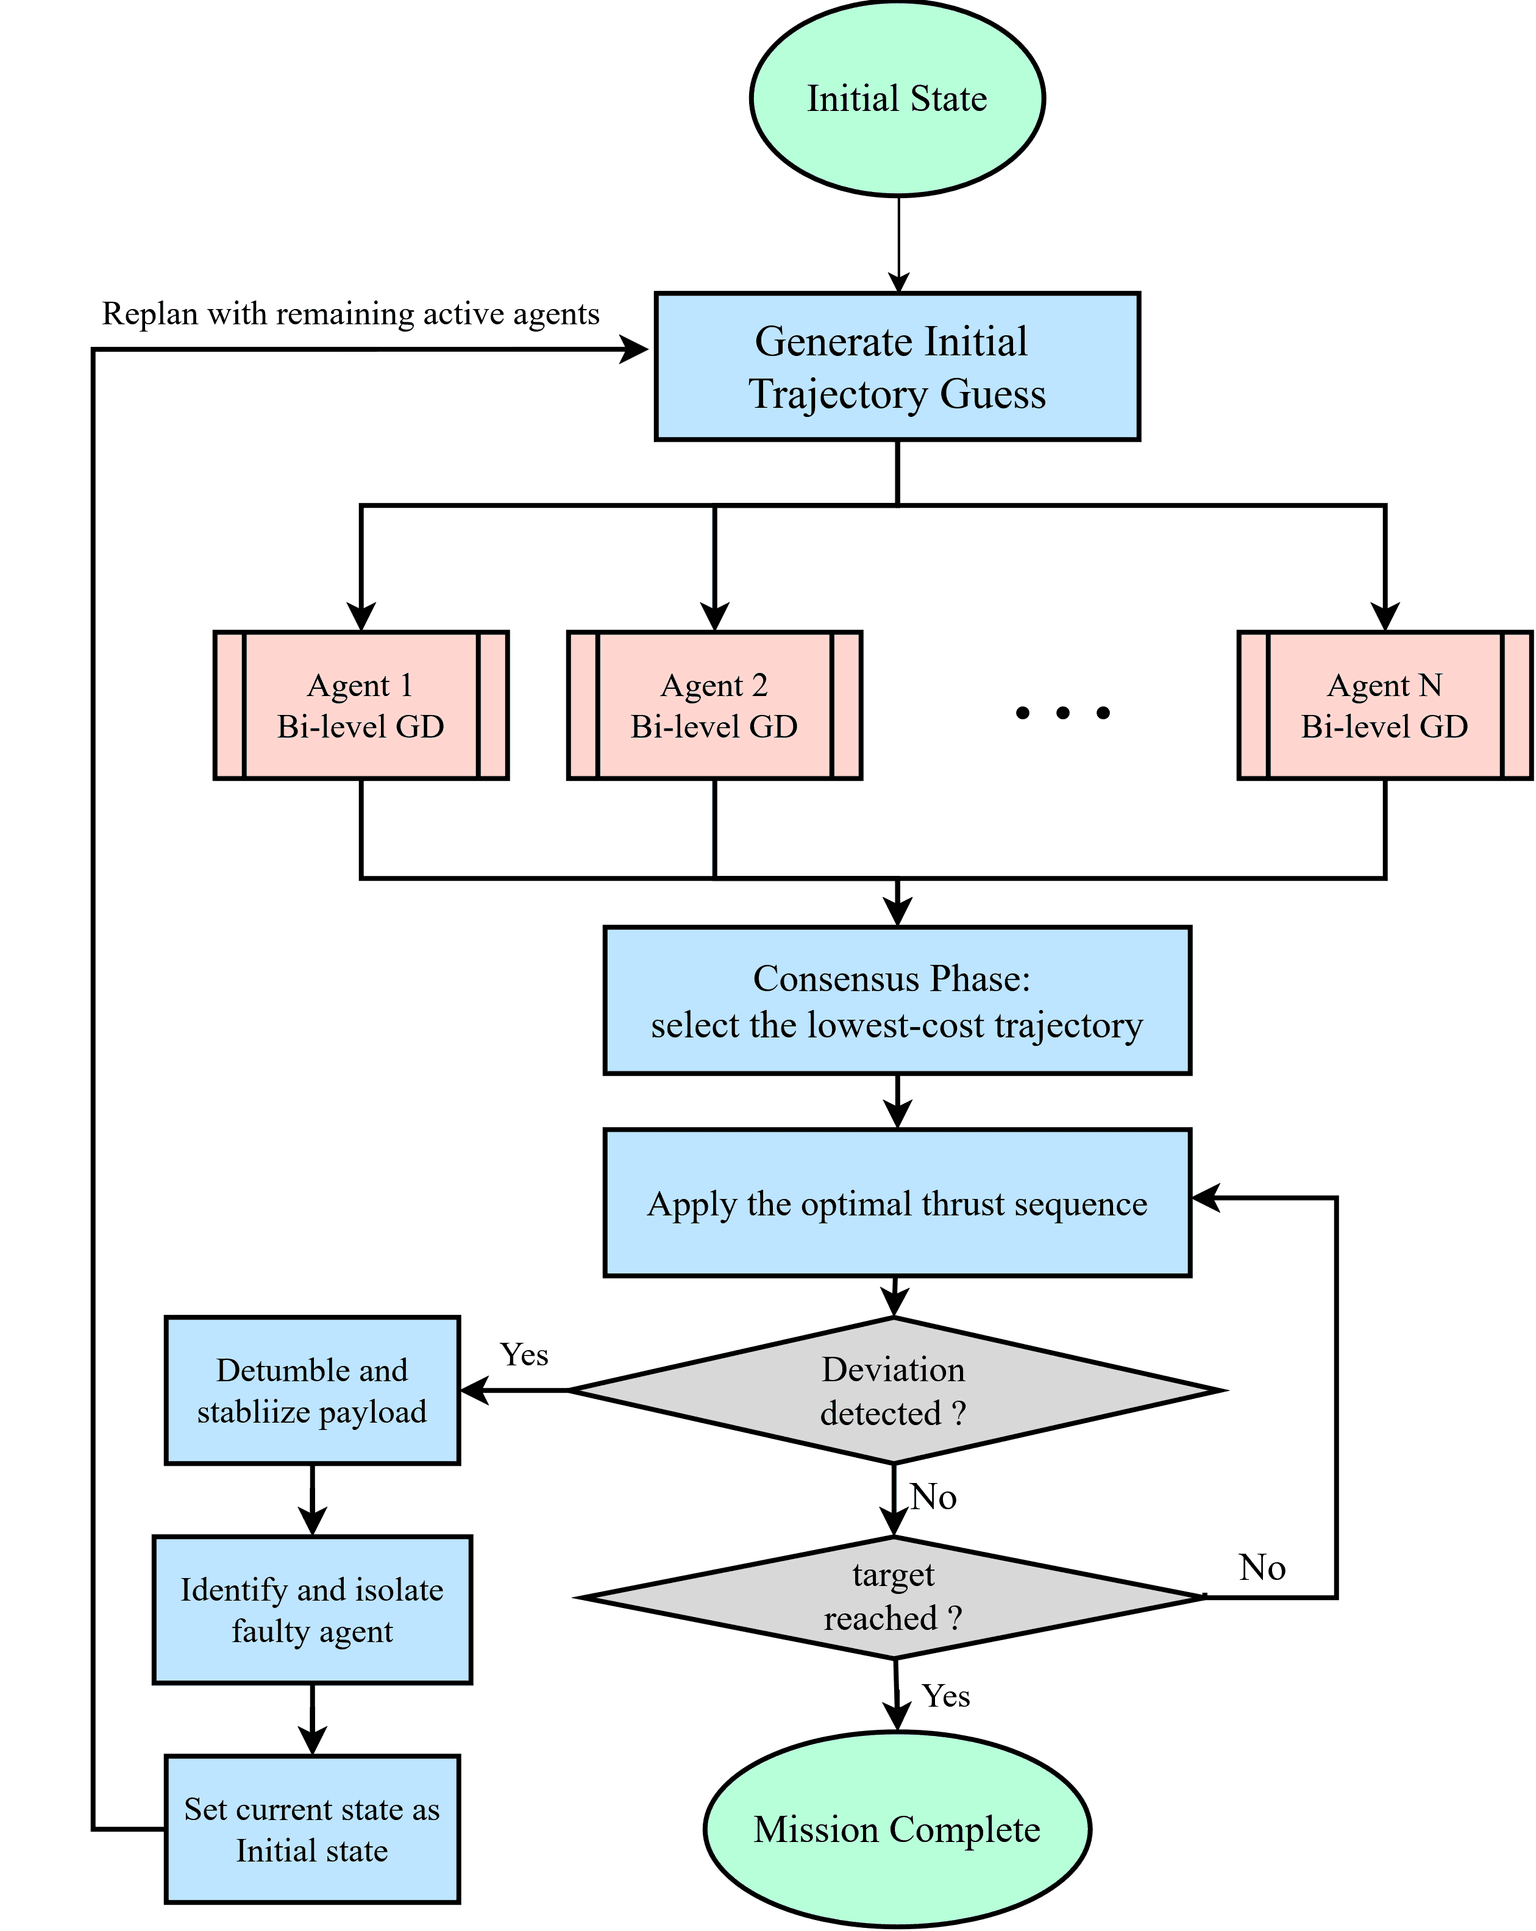
The paper presents a decentralized bi-level optimization framework for swarms of small spacecraft transporting a rigid payload. It separates convex thrust allocation from an outer search over payload torque trajectories, using exact gradients to find fuel-efficient solutions without requiring full nonlinear-program convergence. The authors report theoretical convergence guarantees and validate the method in extensive Monte Carlo simulations, including closed-loop recovery from in-flight faults; short-timescale performance scales with the number of agents.

翻译待处理 · 英文摘要
SCOPE: Scene-graph Construction Optimized by Plan Error-correction for Robot Long-term Planning Datasets

SCOPE: Scene-graph Construction Optimized by Plan Error-correction for Robot Long-term Planning Datasets

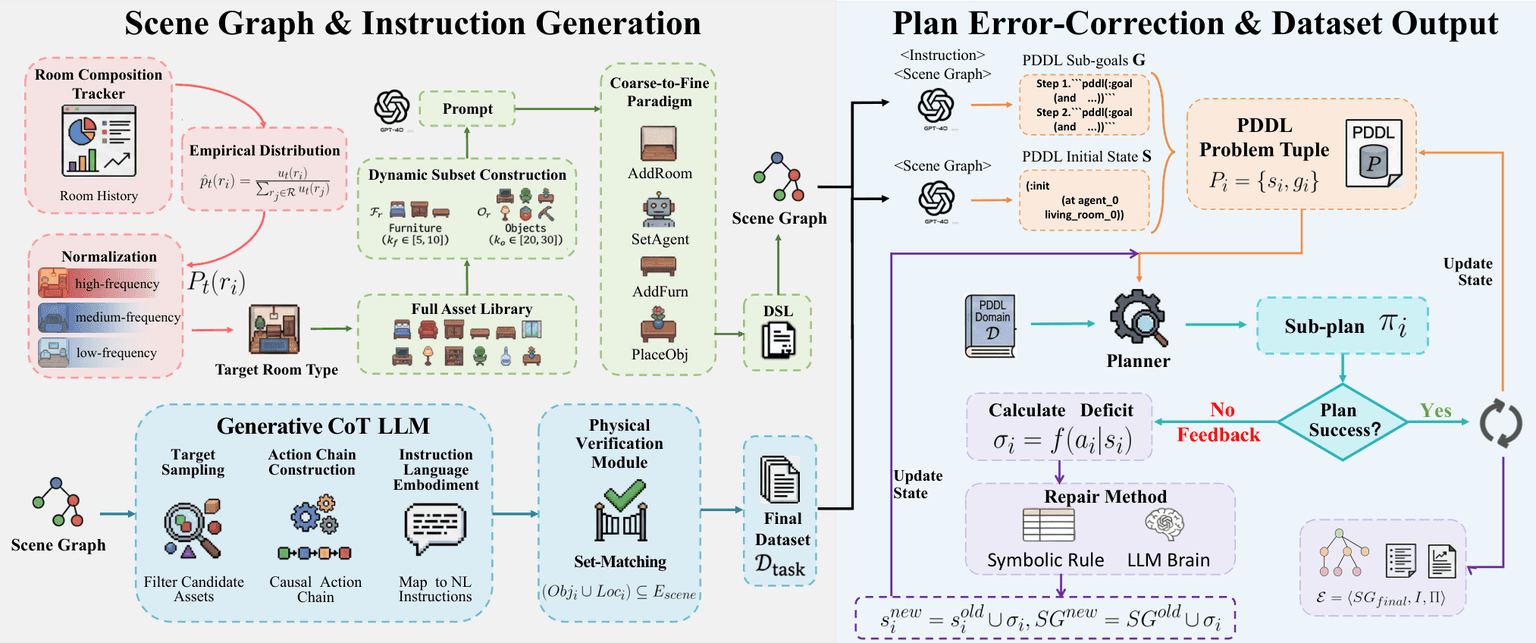
SCOPE is an automated framework for generating diverse, executable task-and-motion-planning datasets for robots. It uses planner execution failures to correct logical inconsistencies in scene graphs, aiming to ensure plans are physically feasible. In experiments, data generated by SCOPE improved a fine-tuned downstream TAMP model’s success rate by an absolute 12.33% over a counterpart trained on DELTA-generated data.

翻译待处理 · 英文摘要
VecTile: A Low-Cost Flexible Tactile Array for 3-DoF Force Sensing

VecTile: A Low-Cost Flexible Tactile Array for 3-DoF Force Sensing

VecTile is a 6 mm-thin, flexible tactile array that uses a piezoresistive layer and silicone nubs to distinguish normal from shear forces. A 4×4 array costs less than $35; in single-taxel tests, normal- and shear-force errors were 0.39 N and 0.16 N RMS. The authors demonstrate balloon-safe scalpel contact and improved Diffusion Policy-guided power-plug insertion.

翻译待处理 · 英文摘要
CoHelix: Event-Based Multi-Propeller Rotation-Rate Tracking with Shared Projective Geometry

CoHelix: Event-Based Multi-Propeller Rotation-Rate Tracking with Shared Projective Geometry

CoHelix is a recursive event-camera filter that tracks rotation rates for four rigidly mounted, coplanar quadcopter propellers while jointly estimating a shared image homography. On moving-camera recordings, it achieved 62.9% lock—time within 2% of synchronized ground truth—versus 39.8% for HelixTrack and 22.2% for EventPro. On a separate target-follower dataset, it reached 95.9% lock using measurement settings selected on the moving-camera data and a fixed initial rate.

翻译待处理 · 英文摘要
GelSlim 5.0: Unifying Vision and Touch with a Single Fingertip Camera

GelSlim 5.0: Unifying Vision and Touch with a Single Fingertip Camera

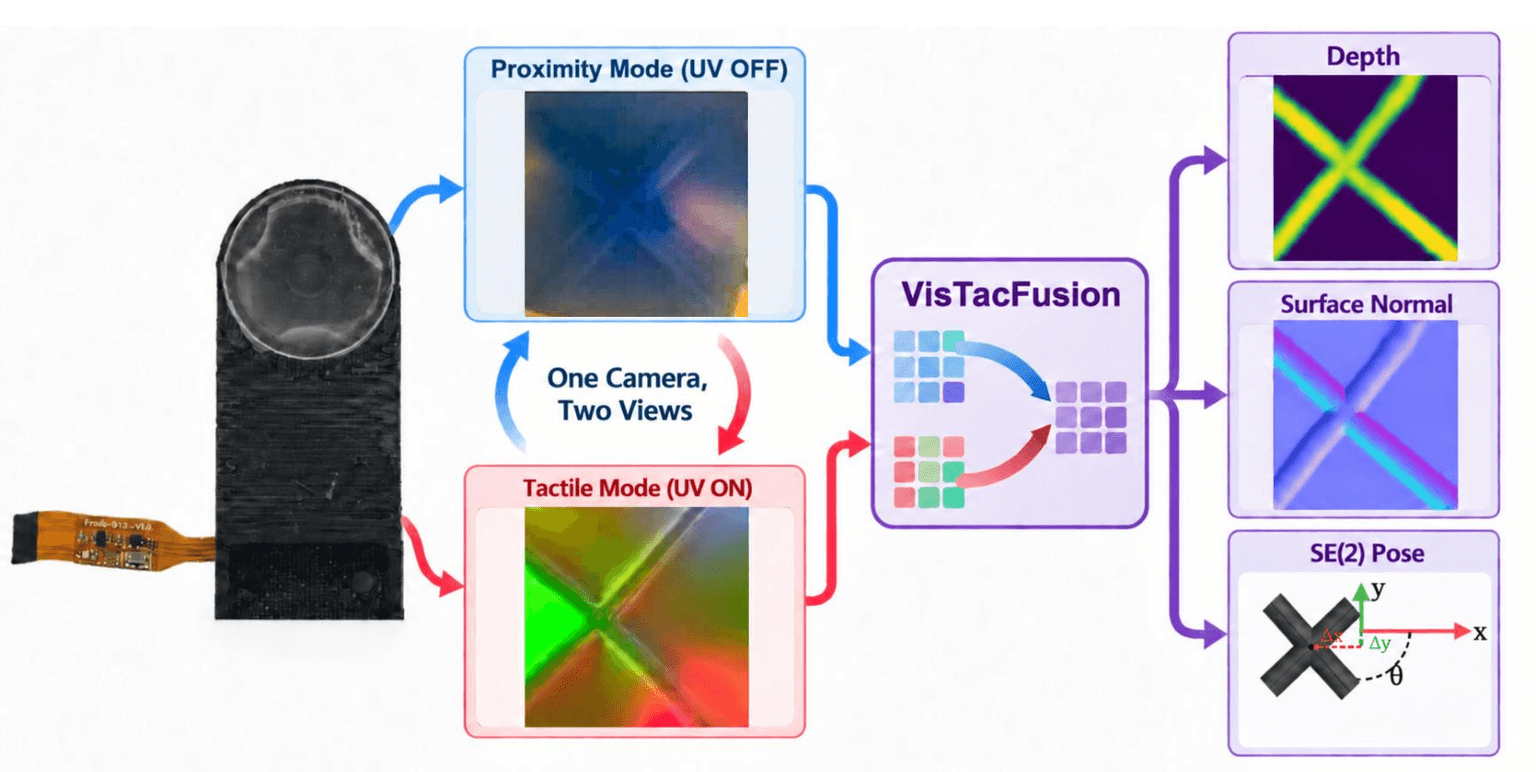
GelSlim 5.0 uses one fixed fingertip camera and a UV-responsive contact layer to capture visual and tactile images sequentially by switching illumination. The VisTacFusion transformer estimates planar object pose and contact depth and surface normals, with modality dropout supporting paired or single-modality inputs. On real validation data from 12 known objects, paired inputs reduced depth MSE by 61.2% versus tactile-only inference and 93.7% versus visual-only inference.

翻译待处理 · 英文摘要
Whole-Body Motion Guided Reference Generation for Uncertainty-Aware Compliant Assistance

Whole-Body Motion Guided Reference Generation for Uncertainty-Aware Compliant Assistance

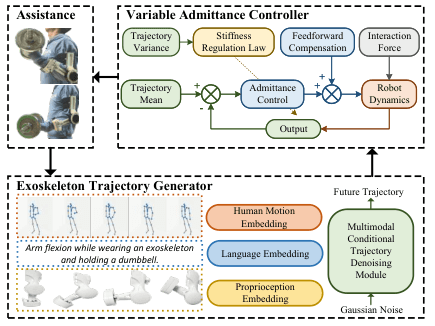
The paper proposes a dual-loop control strategy for exoskeleton assistance. A denoising generator uses whole-body human motion and exoskeleton proprioception, with task descriptions as auxiliary cues, to generate future trajectories. The controller uses the sampled trajectories’ mean as its reference and variance to regulate stiffness through variable admittance control. Experiments report reduced muscle activation versus standard baselines and lower metabolic energy expenditure than the unassisted condition.

翻译待处理 · 英文摘要
Learning Robot Behavior Priors from Non-Robotic Synthetic Data

Learning Robot Behavior Priors from Non-Robotic Synthetic Data

The paper tests whether a Transformer can learn useful robot-action priors from procedurally generated data based on mathematical abstractions of control, without seeing real robot behavior during pretraining. The model achieves non-trivial zero-shot action prediction on unseen physical robot tasks through in-context learning; specialized control priors outperform generic causal priors. A compute-matched model trained on real robot data performs better only on the datasets it saw during training.

翻译待处理 · 英文摘要

Verified published records only; coverage is not a census. arXiv preprints may not be peer reviewed. Official code is linked only after verification.