
Humanoid Mobility via Attention-based Contacts
Translation pending. Showing the saved English brief.
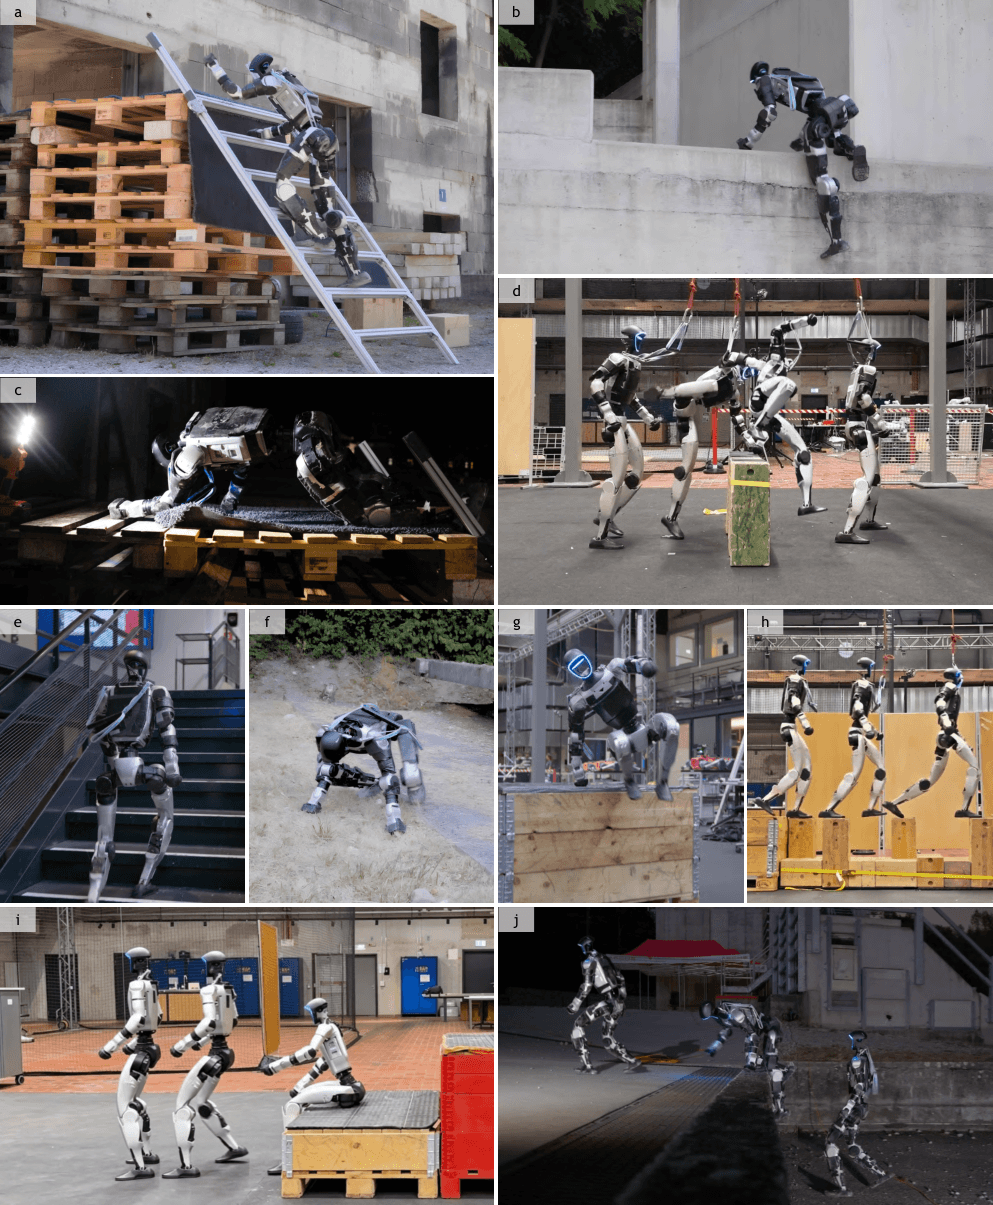
The framework controls a Unitree G1 humanoid using an attention-based contact planner and a contact-conditioned whole-body tracker. Motion data serves only as a training prior; reinforcement-learning fine-tuning helps the policy handle terrain variations beyond the demonstrations. At deployment, it uses onboard observations without reference inputs, enabling one policy to perform tasks including ladder and stair climbing, crawling, vaulting, and stepping-stone traversal.
A short source-linked brief, prepared and localized with AI assistance. The original article is not republished.
Paper details
Junzhe He, Kehan Wen, Chong Zhang, Clemens Schwarke, Zewei Zhang, Kaixian Qu, Siyuan Hu, Matthias Müller, Vladlen Koltun, Marco Hutter
arXiv: 2610.31608 · v1
Preprints may not have completed peer review.