DailyMechaTHE ROBOTICS BRIEFING
⌕
INDEPENDENT SOURCES. A CLEARER PICTURE.Sunday, October 25, 2026
THE DAILY BRIEF

机器人最新动态

News, research and the machines
moving the field forward.

重置
Eka Robotics raises $150M to scale its vision-force-action model for robots

Eka Robotics raises $150M to scale its vision-force-action model for robots

Eka Robotics announced a $150 million Series A to scale its vision-force-action model and customer deployments. The company says it trains the model with simulation and large-scale reinforcement learning to help robots generalize dexterous manipulation across objects and conditions. Eka reports roughly 1,500 operations per hour on out-of-training-distribution object picking, and says its robots can also screw in light bulbs and insert wires.

翻译待处理 · 英文摘要
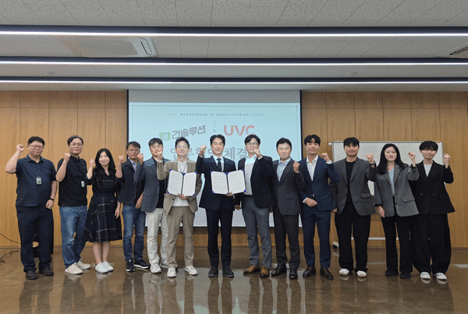
Gunsolution and UBC Plan AI and Digital-Twin Manufacturing Automation Platform

Gunsolution and UBC Plan AI and Digital-Twin Manufacturing Automation Platform

Gunsolution and UBC signed an MOU to develop and jointly commercialize an AI-based autonomous-manufacturing solution combining Gunsolution’s GUNNOS operating system with UBC’s OCTOPUS platform. The planned system links digital-twin analysis and validation of processes and robot-work scenarios with control and operation of robots and equipment on factory floors. The companies also plan joint sales in Korea and overseas; the article reports no completed deployment of this combined solution.

翻译待处理 · 英文摘要
Webinar to discuss how the FCC robotics ruling affects automation buyers

Webinar to discuss how the FCC robotics ruling affects automation buyers

Vecna Robotics, Locus Robotics, and the Association for Advancing Automation will discuss how the FCC’s restrictions on certain foreign-made advanced robots could affect automation buyers. The free webinar, scheduled for October 27, 2026, will cover which robots and companies are affected, connected-system risks, long-term supportability, supply-chain resilience, and acquisition and service strategies. Vecna Robotics says its U.S.-made systems are not directly affected by the ruling.

翻译待处理 · 英文摘要
Generative Bionics plans Italian Physical AI Data Factory for humanoids

Generative Bionics plans Italian Physical AI Data Factory for humanoids

Generative Bionics plans a 5,000-square-meter Physical AI Data Factory in Italy, targeted to become operational by Q4 2027. Fleets of its GENE.01 humanoid will perform industrial tasks in reproduced work environments, collecting vision, motion, and full-body tactile data. The company says physical data and digital-twin simulations will support training and validation before customer deployment; AMD is its planned AI infrastructure partner. The facility is an announced plan, not an operational site.

翻译待处理 · 英文摘要
Huriot Robotics and Hokushō Korea Partner on Logistics Automation

Huriot Robotics and Hokushō Korea Partner on Logistics Automation

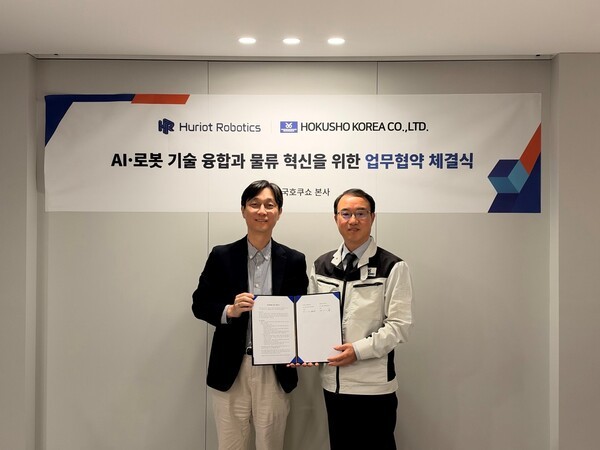
Huriot Robotics and Hokushō Korea signed an MOU to explore joint logistics-automation projects, connecting Hokushō’s vertical conveyors and PAS sorters with Huriot’s autonomous mobile robots (AMRs), automated guided forklifts (AGFs), and laser-guided vehicles (LGVs). They plan to jointly review customer requirements and propose integrated systems linking fixed equipment with mobile robots. The article announces a cooperation plan, not a completed deployment or measured result.

翻译待处理 · 英文摘要
South Korea plans regulatory changes to accelerate autonomous vehicles and mobile robots

South Korea plans regulatory changes to accelerate autonomous vehicles and mobile robots

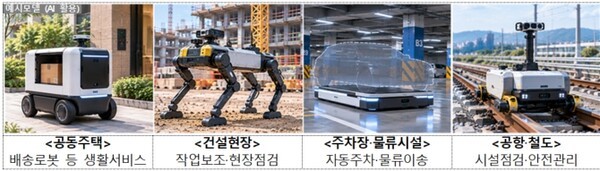
South Korea’s Ministry of Land, Infrastructure and Transport announced plans to ease approvals and establish operating rules for driverless vehicles and mobile robots. Measures include a fast-track permit for qualifying autonomous vehicles, a proposed service-operator framework for remote monitoring and emergency response, and sector-specific rules for robots in apartments, construction sites, parking and logistics facilities, and airports and railways. The plans are intended to move technologies from trials toward commercial services; their effects depend on future regulations and implementation.

翻译待处理 · 英文摘要

The work presents GENESIS-Handover, a method for selecting task-specific robot-to-human handover configurations, and describes deploying the system on a mobile manipulator.

翻译待处理 · 英文摘要

The video presents an MW-R16S autonomous reach forklift for warehouse automation, including high-rack storage and pallet pickup and transport.

翻译待处理 · 英文摘要

The video presents JAKA S12 and A12L collaborative robots performing gearbox assembly and visual inspection in a coordinated workflow.

翻译待处理 · 英文摘要

研究动态

视图 论文 →
Sensorimotor Alignment: A Platonic Proxy for Embodied Policy Success

Sensorimotor Alignment: A Platonic Proxy for Embodied Policy Success

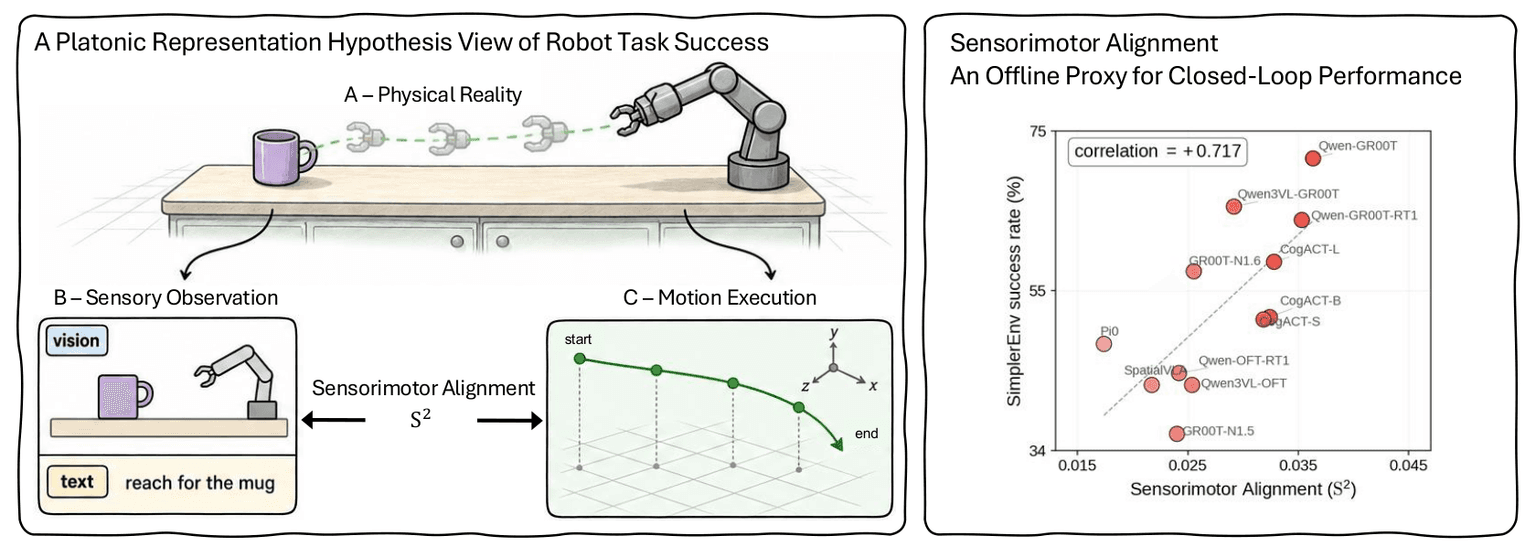
The paper proposes Sensorimotor Alignment (S²), a training-free offline metric that compares a model’s sensory representations with the geometry of physical motion, represented by end-effector trajectories. Across 12 vision-language-action models, S² positively correlates with downstream robot task success. The authors present it as a low-cost way to prioritize models and identify promising vision-language backbones before fine-tuning or costly closed-loop evaluation.

翻译待处理 · 英文摘要
OpenTac: An Open Ecosystem for Customizable, Scalable, and Transferable 3D Tactile Sensing

OpenTac: An Open Ecosystem for Customizable, Scalable, and Transferable 3D Tactile Sensing

OpenTac combines a scalable resistive tactile skin with CAD, simulation, and data-acquisition tools for robot applications. Its structured deformable overlay encodes normal force and local shear from taxel responses. The authors report fabricating more than 30 sensor designs and demonstrate tactile feedback control and manipulation-policy learning on four real-world robot embodiments. Adaptive readout reaches kilohertz rates and is 19.2× faster than full-array raster scanning at 16 sampled taxels per update on a 1024-taxel skin.

翻译待处理 · 英文摘要
AI 插画 · Extending Harmonic Function Methods via Root Locus for Coordinated Path GenerationAI 插画

Extending Harmonic Function Methods via Root Locus for Coordinated Path Generation

This preprint studies coordinated paths for interchangeable robots and goals in planar spaces with polygonal obstacles. The proposed construction uses conformal mapping and a generalized root locus to derive robot-goal assignments and paths. The authors describe safety tests and simulated examples. DailyMecha has summarized the abstract, without independently validating the mathematical claims.

翻译待处理 · 英文摘要