
OpenArm
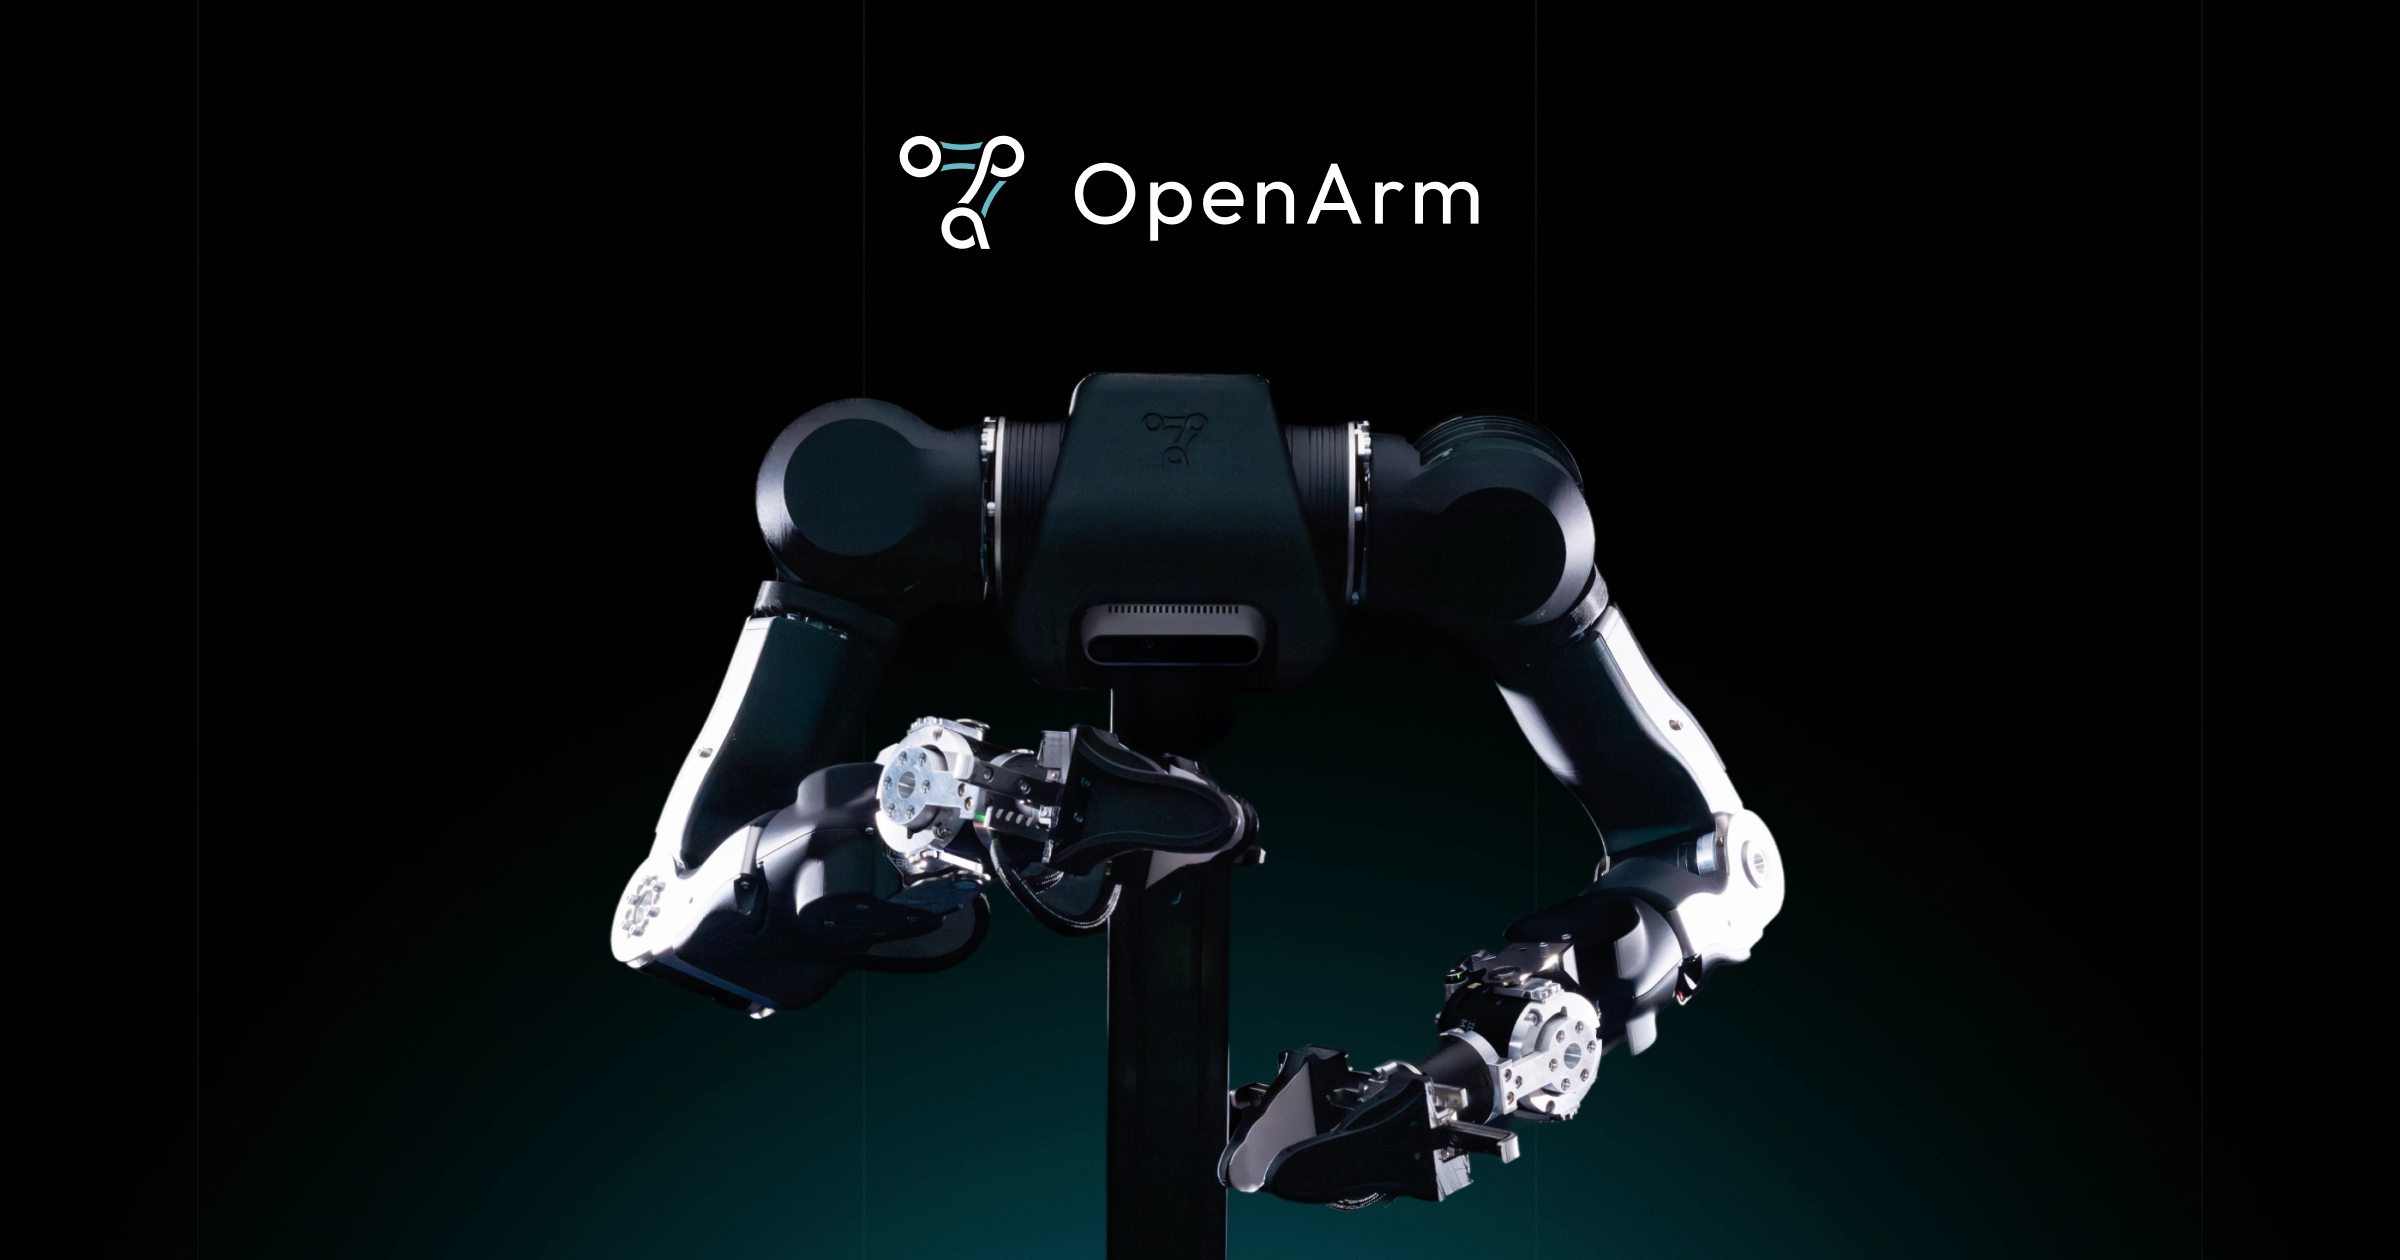
접촉이 많은 환경에서 물리적 AI 연구 및 배포를 위한 완전한 오픈소스 휴머노이드 팔.
출처에 기반한 짧은 요약입니다. 기사 전문을 재게시하지 않으며 AI의 도움을 받아 작성·번역합니다.
공개 저장소와 라이선스
GitHub · enactic/openarmApache-2.0
Curated institutional project; actual implementation directories and root license checked at the official repository. Hardware, data and weights retain separate terms.