Sensorimotor Alignment: A Platonic Proxy for Embodied Policy Success
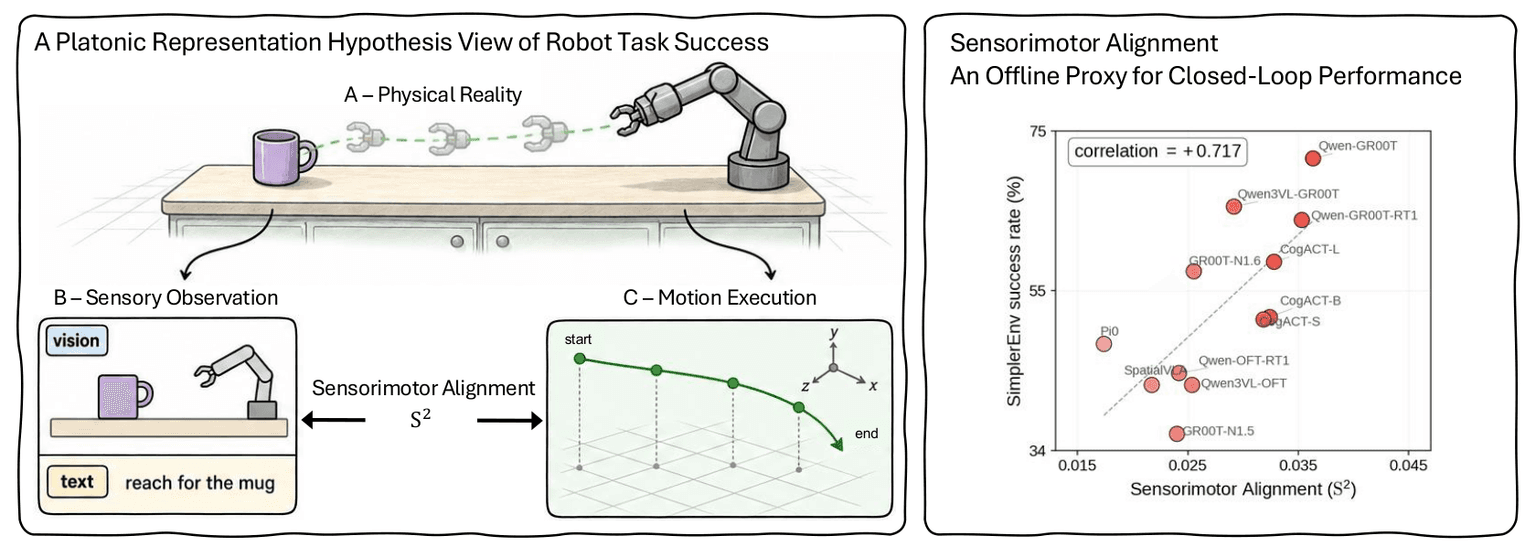
The paper proposes Sensorimotor Alignment (S²), a training-free offline metric that compares a model’s sensory representations with the geometry of physical motion, represented by end-effector trajectories. Across 12 vision-language-action models, S² positively correlates with downstream robot task success. The authors present it as a low-cost way to prioritize models and identify promising vision-language backbones before fine-tuning or costly closed-loop evaluation.
翻訳待ち · 英語の要約