
Whole-Body Motion Guided Reference Generation for Uncertainty-Aware Compliant Assistance
Traducción pendiente. Se muestra el resumen en inglés.
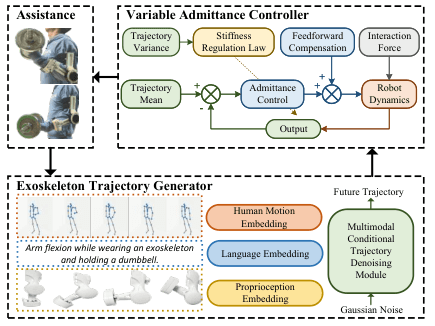
The paper proposes a dual-loop control strategy for exoskeleton assistance. A denoising generator uses whole-body human motion and exoskeleton proprioception, with task descriptions as auxiliary cues, to generate future trajectories. The controller uses the sampled trajectories’ mean as its reference and variance to regulate stiffness through variable admittance control. Experiments report reduced muscle activation versus standard baselines and lower metabolic energy expenditure than the unassisted condition.
A short source-linked brief, prepared and localized with AI assistance. The original article is not republished.
Paper details
Muyuan Ma, Long Cheng, Lijun Han, Haotian Zhai, Xinpan Meng, Xiuze Xia, Houcheng Li, Zeyu Liu
arXiv: 2610.31302 · v1
Preprints may not have completed peer review.