DailyMechaTHE ROBOTICS BRIEFING
⌕
INDEPENDENT SOURCES. A CLEARER PICTURE.Sunday, October 25, 2026
DAILYMECHA / 论文

论文

Fresh research. Original abstracts preserved.

重置
Latest submittedRecently updated
4 records · newest first
网格列表
OpenTac: An Open Ecosystem for Customizable, Scalable, and Transferable 3D Tactile Sensing

OpenTac: An Open Ecosystem for Customizable, Scalable, and Transferable 3D Tactile Sensing

OpenTac combines a scalable resistive tactile skin with CAD, simulation, and data-acquisition tools for robot applications. Its structured deformable overlay encodes normal force and local shear from taxel responses. The authors report fabricating more than 30 sensor designs and demonstrate tactile feedback control and manipulation-policy learning on four real-world robot embodiments. Adaptive readout reaches kilohertz rates and is 19.2× faster than full-array raster scanning at 16 sampled taxels per update on a 1024-taxel skin.

翻译待处理 · 英文摘要
Progress Probes P²: Lightweight Runtime Monitoring for Vision-Language-Action Models

Progress Probes P²: Lightweight Runtime Monitoring for Vision-Language-Action Models

Progress Probes trains linear probes on activations from the open-source π0.5 vision-language-action model, using successful demonstrations to estimate task progress. At runtime, the monitor flags executions whose estimated progress lags or deviates from the expected trajectory. Across simulated and real-world manipulation tasks, the method was competitive with or outperformed VLM-based monitors and methods trained with failure data, without requiring an external foundation model.

翻译待处理 · 英文摘要
VecTile: A Low-Cost Flexible Tactile Array for 3-DoF Force Sensing

VecTile: A Low-Cost Flexible Tactile Array for 3-DoF Force Sensing

VecTile is a 6 mm-thin, flexible tactile array that uses a piezoresistive layer and silicone nubs to distinguish normal from shear forces. A 4×4 array costs less than $35; in single-taxel tests, normal- and shear-force errors were 0.39 N and 0.16 N RMS. The authors demonstrate balloon-safe scalpel contact and improved Diffusion Policy-guided power-plug insertion.

翻译待处理 · 英文摘要
GelSlim 5.0: Unifying Vision and Touch with a Single Fingertip Camera

GelSlim 5.0: Unifying Vision and Touch with a Single Fingertip Camera

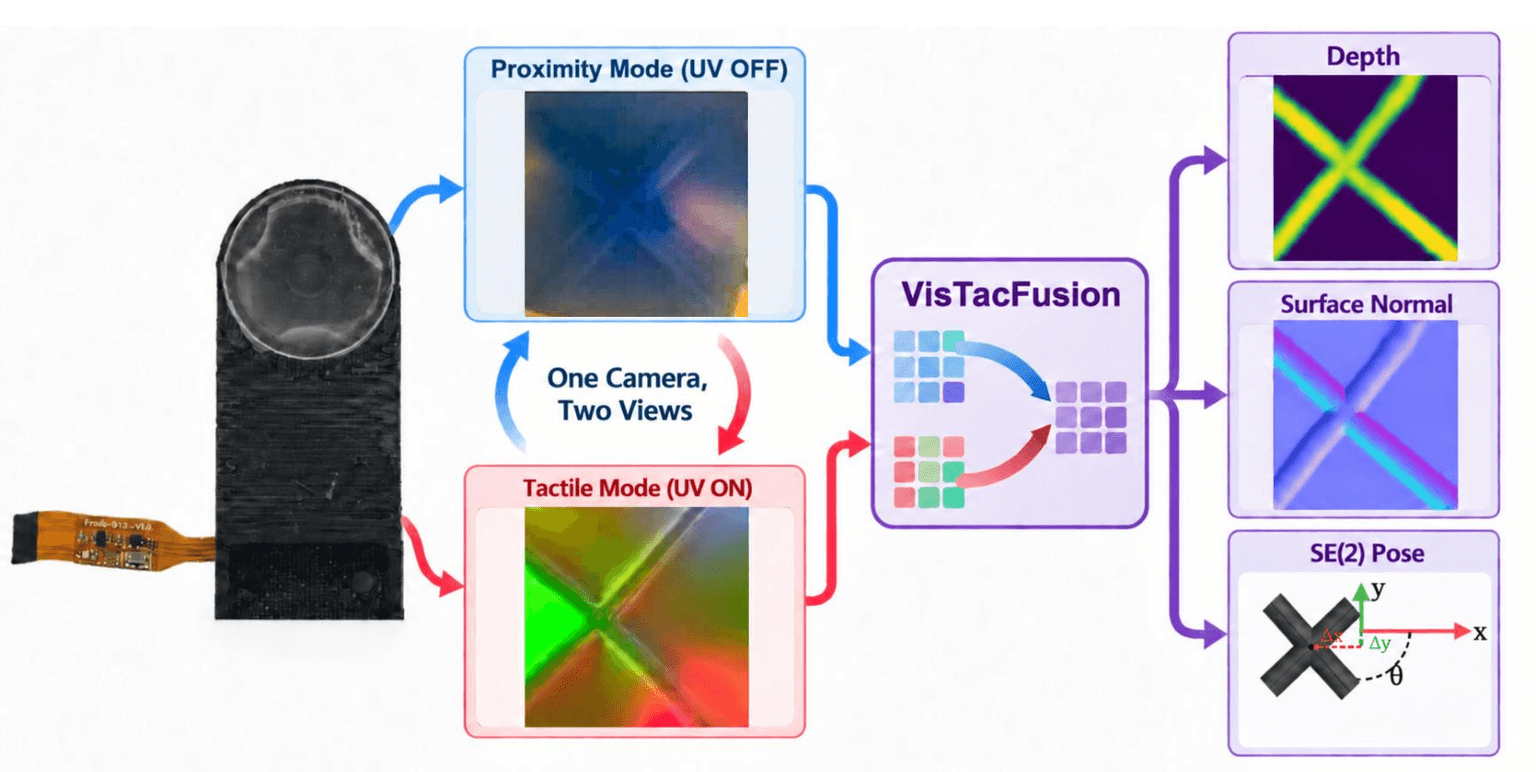
GelSlim 5.0 uses one fixed fingertip camera and a UV-responsive contact layer to capture visual and tactile images sequentially by switching illumination. The VisTacFusion transformer estimates planar object pose and contact depth and surface normals, with modality dropout supporting paired or single-modality inputs. On real validation data from 12 known objects, paired inputs reduced depth MSE by 61.2% versus tactile-only inference and 93.7% versus visual-only inference.

翻译待处理 · 英文摘要

Verified published records only; coverage is not a census. arXiv preprints may not be peer reviewed. Official code is linked only after verification.