
Consistent Distributed Invariant EKF SLAM with Point and Object Features
번역을 준비 중입니다. 저장된 영어 요약을 먼저 표시합니다.
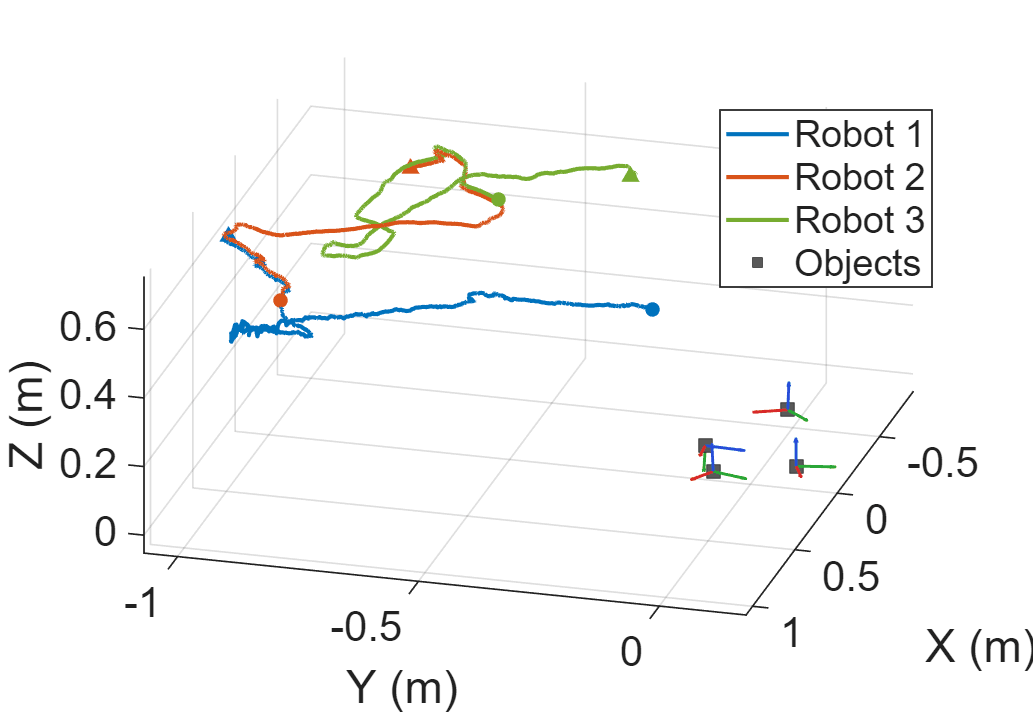
Joint-CI is a distributed fusion method for multi-robot right-invariant EKF SLAM with point features, object features, or both. It uses a neighboring robot’s posterior and an inter-robot observation to construct a joint estimate in the receiving robot’s error coordinates, then applies partial-state covariance intersection. The paper reports preserved global rotation and translation unobservability and first-order covariance consistency; simulations and a dataset-derived experiment show improved accuracy with mildly conservative uncertainty.
출처에 기반한 짧은 요약입니다. 기사 전문을 재게시하지 않으며 AI의 도움을 받아 작성·번역합니다.
논문 정보
Mengya Xu, Xianjia Yu, Ha Sier, Shoudong Huang, Tomi Westerlund
arXiv: 2610.31221 · v1
사전 공개 논문은 동료 심사를 마치지 않았을 수 있습니다.