
Consistent Distributed Invariant EKF SLAM with Point and Object Features
翻訳準備中です。英語の要約を表示しています。
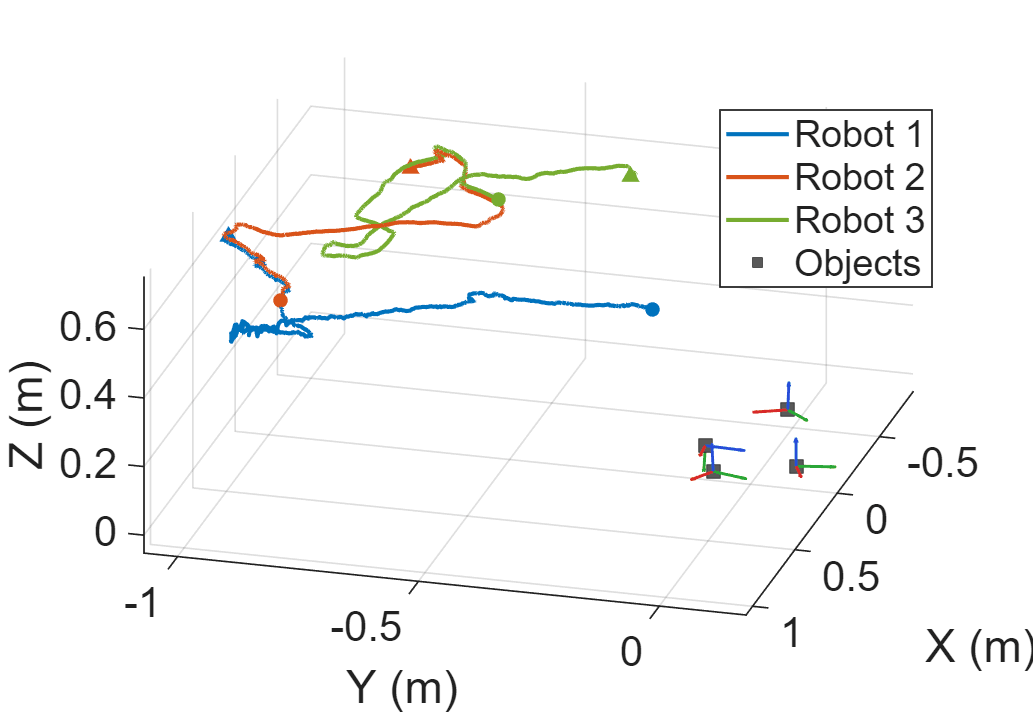
Joint-CI is a distributed fusion method for multi-robot right-invariant EKF SLAM with point features, object features, or both. It uses a neighboring robot’s posterior and an inter-robot observation to construct a joint estimate in the receiving robot’s error coordinates, then applies partial-state covariance intersection. The paper reports preserved global rotation and translation unobservability and first-order covariance consistency; simulations and a dataset-derived experiment show improved accuracy with mildly conservative uncertainty.
A short source-linked brief, prepared and localized with AI assistance. The original article is not republished.
Paper details
Mengya Xu, Xianjia Yu, Ha Sier, Shoudong Huang, Tomi Westerlund
arXiv: 2610.31221 · v1
Preprints may not have completed peer review.