
☆ 1087d: insufficient historyOct 25, 2026Project details
Selected institutions. Verified materials.
Licenses shown per artifact.
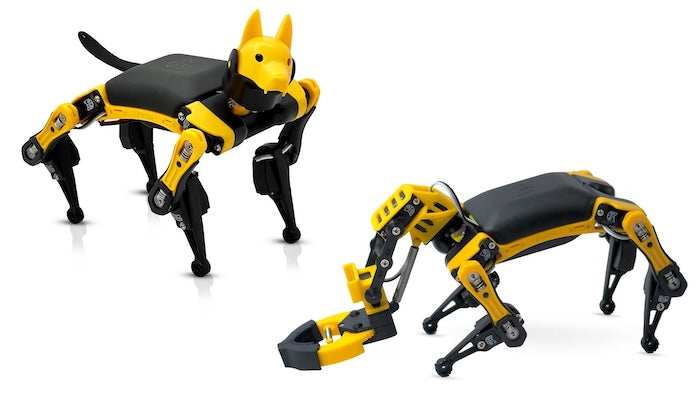
An open source quadruped robot pet framework for developing Boston Dynamics-style four-legged robots that are perfect for STEM, coding & robotics education, IoT robotics applications, AI-enhanced robotics application services, research, and DIY robotics kit development.
Released Date unconfirmed · Checked Oct 25, 2026StanfordQuadruped
Released Date unconfirmed · Checked Oct 25, 2026Official institutions, actual files and per-artifact licenses are checked. Hardware, datasets and model weights may have separate terms.