
☆ 1087d: insufficient historyOct 25, 2026프로젝트 정보
Selected institutions. Verified materials.
Licenses shown per artifact.
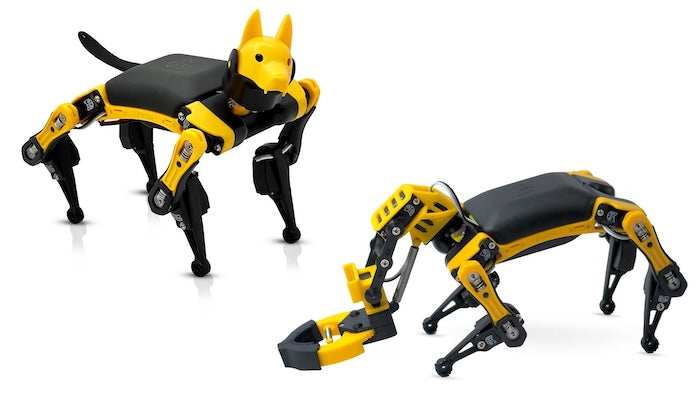
Boston Dynamics 스타일의 사족 보행 로봇을 개발하기 위한 오픈 소스 사족 보행 로봇 반려동물 프레임워크입니다. STEM, 코딩 및 로보틱스 교육, IoT 로보틱스 애플리케이션, AI 강화 로보틱스 애플리케이션 서비스, 연구 및 DIY 로보틱스 키트 개발에 적합합니다.
Released Date unconfirmed · Checked Oct 25, 2026Official institutions, actual files and per-artifact licenses are checked. Hardware, datasets and model weights may have separate terms.