
Humanoid Mobility via Attention-based Contacts
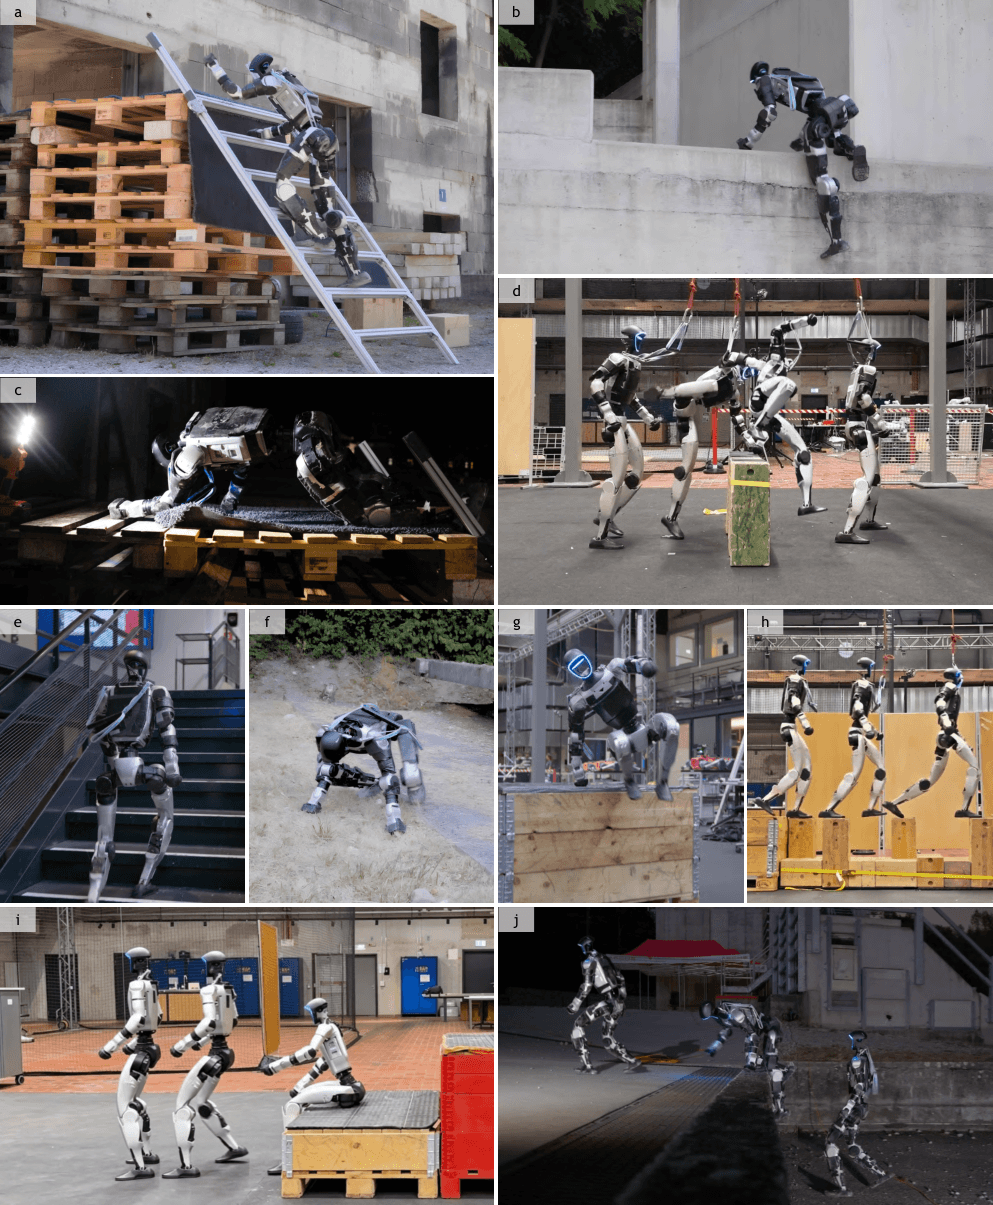
The framework controls a Unitree G1 humanoid using an attention-based contact planner and a contact-conditioned whole-body tracker. Motion data serves only as a training prior; reinforcement-learning fine-tuning helps the policy handle terrain variations beyond the demonstrations. At deployment, it uses onboard observations without reference inputs, enabling one policy to perform tasks including ladder and stair climbing, crawling, vaulting, and stepping-stone traversal.
Traducción pendiente · Resumen en inglés