
Decentralized Bi-Level Optimization for Cooperative Orbital Transportation of a Rigid Payload
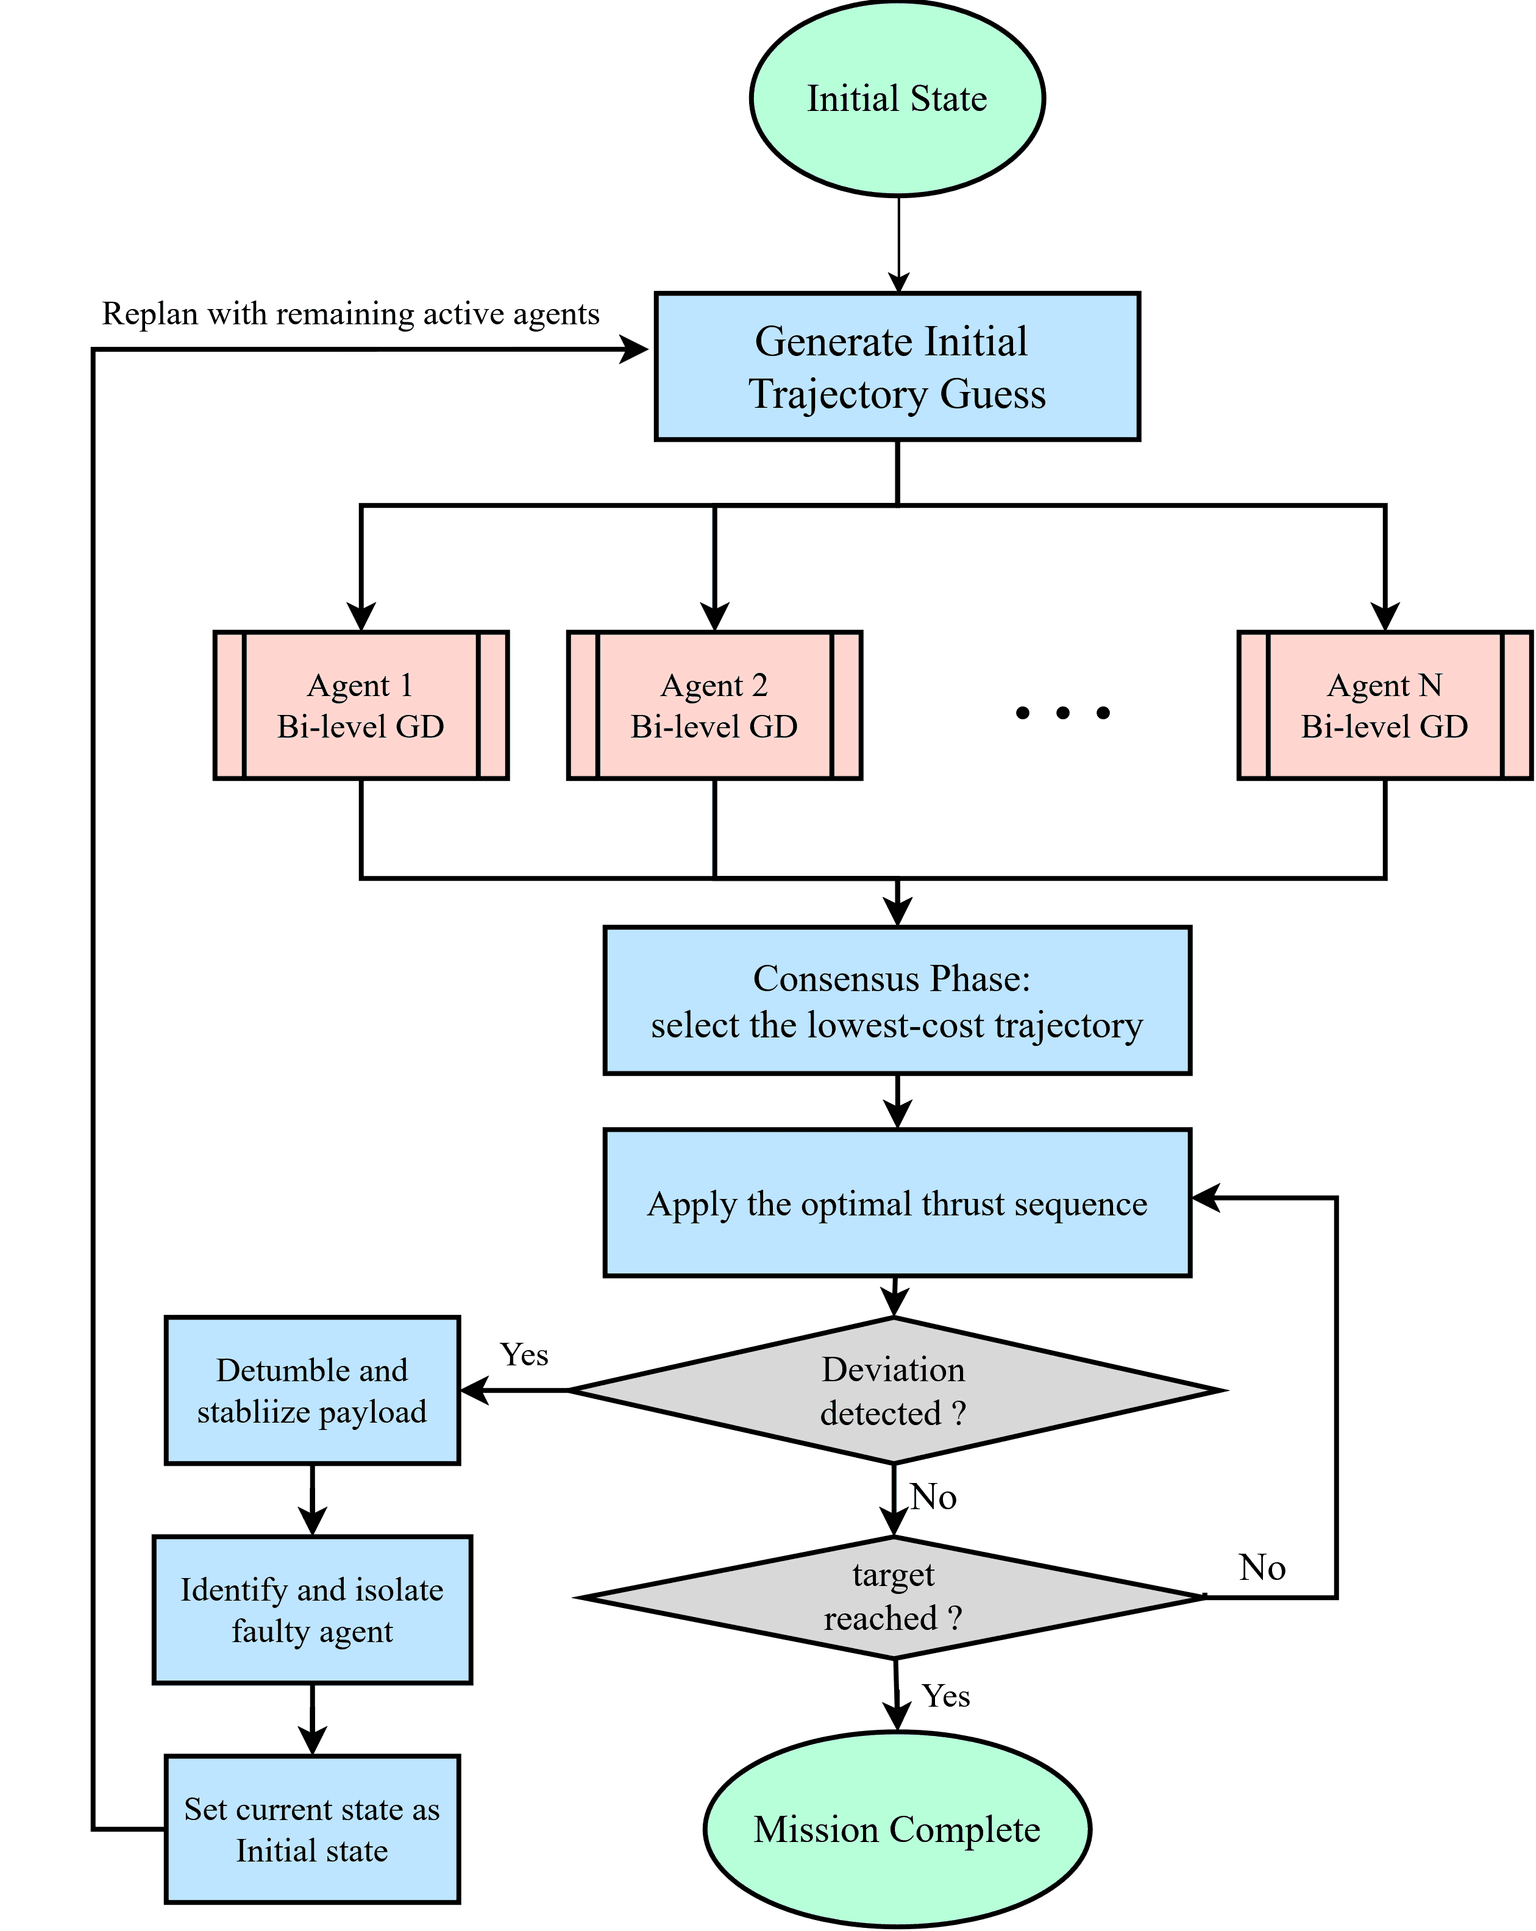
The paper presents a decentralized bi-level optimization framework for swarms of small spacecraft transporting a rigid payload. It separates convex thrust allocation from an outer search over payload torque trajectories, using exact gradients to find fuel-efficient solutions without requiring full nonlinear-program convergence. The authors report theoretical convergence guarantees and validate the method in extensive Monte Carlo simulations, including closed-loop recovery from in-flight faults; short-timescale performance scales with the number of agents.
A short source-linked brief, prepared and localized with AI assistance. The original article is not republished.
Paper details
Sidhdharth D. Sikka, Revathy Ravuri, Hei Yin Jowett Chan, Tim Echtermeyer, Shaoshuai Mou
arXiv: 2610.31562 · v1
Preprints may not have completed peer review.