
Reactive Task-Oriented Robot-Human Handovers via Generative Hypothesis Selection
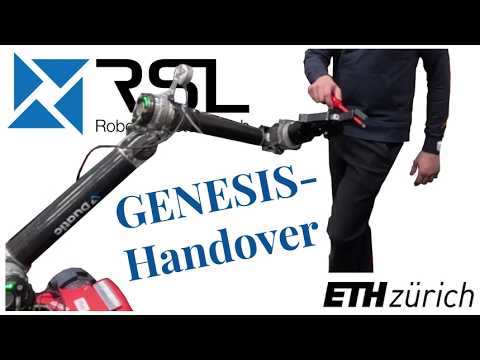
The work presents GENESIS-Handover, a method for selecting task-specific robot-to-human handover configurations, and describes deploying the system on a mobile manipulator.
Original source · Robotic Systems Lab: Legged Robotics at ETH Zürich
A short source-linked brief, prepared and localized with AI assistance. The original article is not republished.