
DailyMechaTHE ROBOTICS BRIEFING
⌕
INDEPENDENT SOURCES. A CLEARER PICTURE.Sunday, October 25, 2026
DAILYMECHA / 论文

论文

Fresh research. Original abstracts preserved.

重置
Latest submittedRecently updated
3 records · newest first
网格列表
AI 插画 · Extending Harmonic Function Methods via Root Locus for Coordinated Path GenerationAI 插画

Extending Harmonic Function Methods via Root Locus for Coordinated Path Generation

This preprint studies coordinated paths for interchangeable robots and goals in planar spaces with polygonal obstacles. The proposed construction uses conformal mapping and a generalized root locus to derive robot-goal assignments and paths. The authors describe safety tests and simulated examples. DailyMecha has summarized the abstract, without independently validating the mathematical claims.

翻译待处理 · 英文摘要
Decentralized Bi-Level Optimization for Cooperative Orbital Transportation of a Rigid Payload

Decentralized Bi-Level Optimization for Cooperative Orbital Transportation of a Rigid Payload

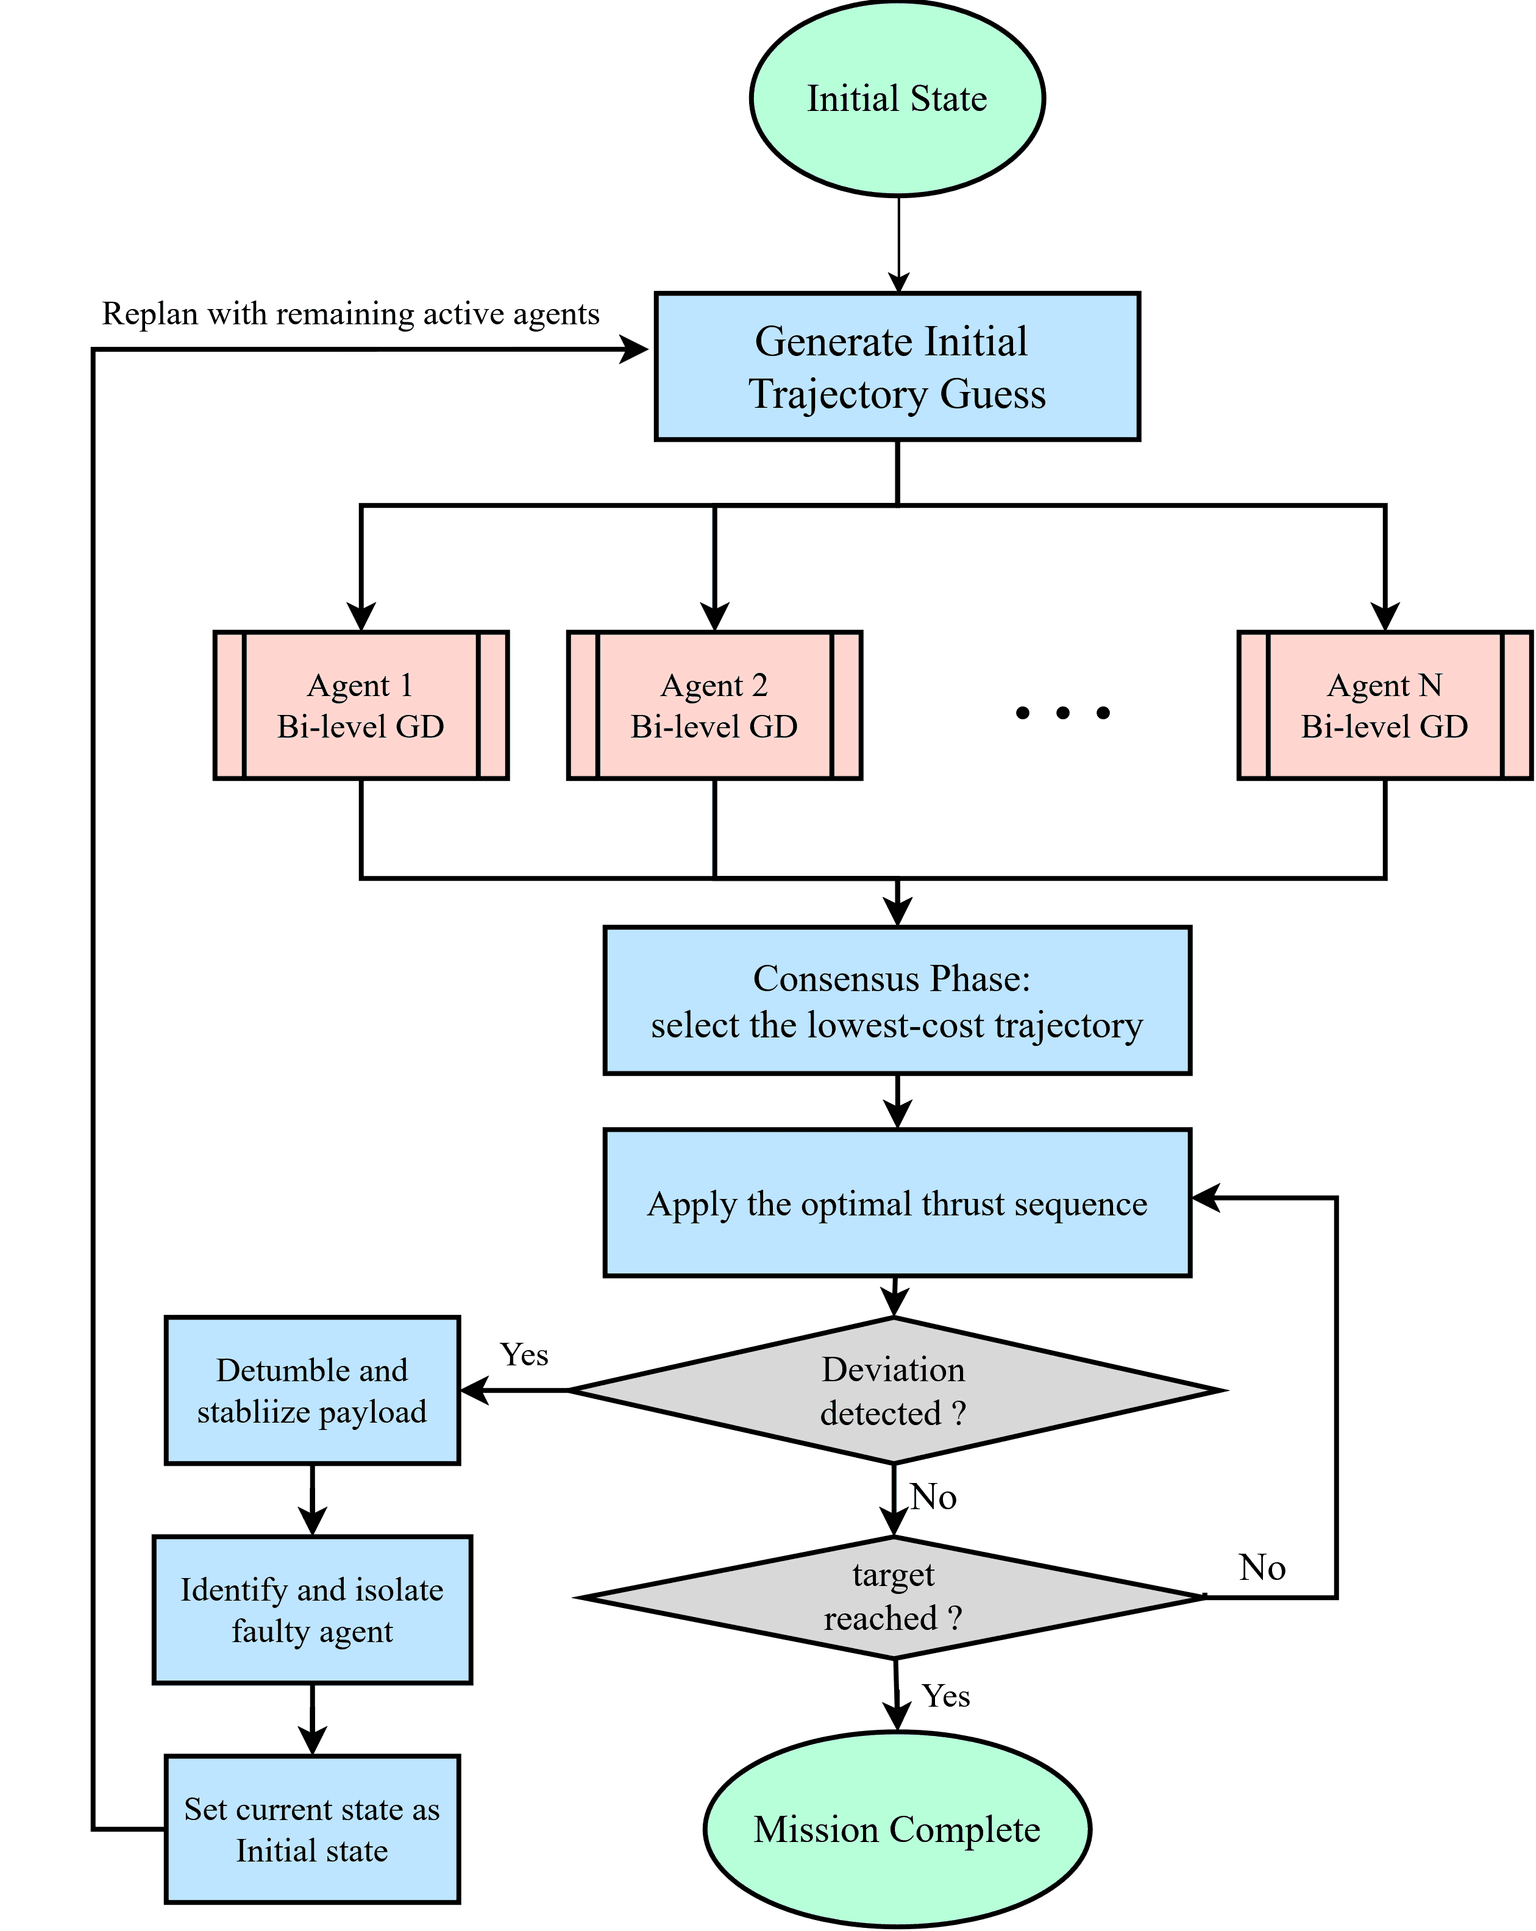
The paper presents a decentralized bi-level optimization framework for swarms of small spacecraft transporting a rigid payload. It separates convex thrust allocation from an outer search over payload torque trajectories, using exact gradients to find fuel-efficient solutions without requiring full nonlinear-program convergence. The authors report theoretical convergence guarantees and validate the method in extensive Monte Carlo simulations, including closed-loop recovery from in-flight faults; short-timescale performance scales with the number of agents.

翻译待处理 · 英文摘要
Whole-Body Motion Guided Reference Generation for Uncertainty-Aware Compliant Assistance

Whole-Body Motion Guided Reference Generation for Uncertainty-Aware Compliant Assistance

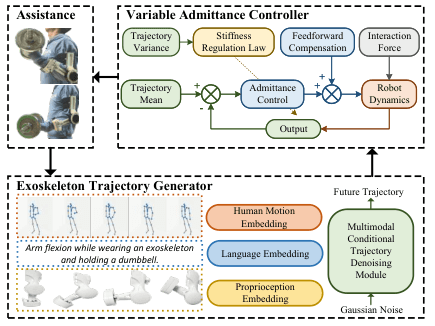
The paper proposes a dual-loop control strategy for exoskeleton assistance. A denoising generator uses whole-body human motion and exoskeleton proprioception, with task descriptions as auxiliary cues, to generate future trajectories. The controller uses the sampled trajectories’ mean as its reference and variance to regulate stiffness through variable admittance control. Experiments report reduced muscle activation versus standard baselines and lower metabolic energy expenditure than the unassisted condition.

翻译待处理 · 英文摘要

Verified published records only; coverage is not a census. arXiv preprints may not be peer reviewed. Official code is linked only after verification.